Uploaded January 2013 | Updated September 2026, 1 week ago
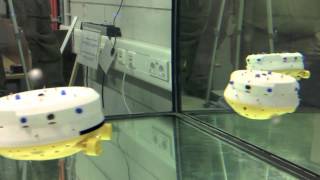
This video shows 4 test runs of a late generation of an evolved shoaling algorithm.
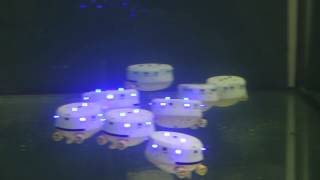
The algorithm was evolved using 2 AUVs, this video shows that the algorithm can also work with 3 AUVs (though it is less efficient).
At this state the evolved algorithm is capable of keeping the AUVs coherent and also letting them move collectively away from the starting point by emergent alignment. This solution presents good solution to the fitness function (coherence+alignment+mobility) that was used for the Evolutionary Algorithm.
Earlier generations of the evolving algorithm can be seen here (with 2 AUVs, as used in the evolution of this algorithm):
Gen10: youtube.com/watch?v=HPPT8pxptxk
Gen436: youtube.com/watch?v=IGgnhgpDyyQ
Gen750: youtube.com/watch?v=poRepPCvH70
The evolvable parameters allowed the AUVs to change their perception and also their reaction to other near AUVs.
This video shows 4 test runs of a late generation of an evolved shoaling algorithm.
The algorithm was evolved using 2 AUVs, this video shows that the algorithm can also work with 3 AUVs (though it is less efficient).
At this state the evolved algorithm is capable of keeping the AUVs coherent and also letting them move collectively away from the starting point by emergent alignment. This solution presents good solution to the fitness function (coherence+alignment+mobility) that was used for the Evolutionary Algorithm.
Earlier generations of the evolving algorithm can be seen here (with 2 AUVs, as used in the evolution of this algorithm):
Gen10: youtube.com/watch?v=HPPT8pxptxk
Gen436: youtube.com/watch?v=IGgnhgpDyyQ
Gen750: youtube.com/watch?v=poRepPCvH70
The evolvable parameters allowed the AUVs to change their perception and also their reaction to other near AUVs.