Uploaded March 2024 | Updated September 2026, 1 hour ago
Video for IROS 2023 submission.
The video presents the paper “Robo-centric ESDF: A Fast and Accurate Whole-body Collision Evaluation Tool for Any-Shape Robotic Planning”
Paper: ieeexplore.ieee.org/document/10342074
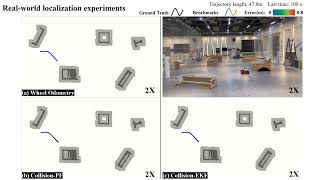
For letting mobile robots travel flexibly through complicated environments, increasing attention has been paid to the whole-body collision evaluation. Most existing works either opt for the conservative corridor-based methods that impose strict requirements on the corridor generation, or ESDF-based methods that suffer from high computational overhead. It is still a great challenge to achieve fast and accurate wholebody collision evaluation. In this paper, we propose a Robocentric ESDF (RC-ESDF) that is pre-built in the robot body frame and is capable of seamlessly applied to any-shape mobile robots, even for those with non-convex shapes. RC-ESDF enjoys lazy collision evaluation, which retains only the minimum information sufficient for whole-body safety constraint and significantly speeds up trajectory optimization. Based on the analytical gradients provided by RC-ESDF, we optimize the position and rotation of robot jointly, with whole-body safety, smoothness, and dynamical feasibility taken into account. Extensive simulation and real-world experiments verified the reliability and generalizability of our method.
Video for IROS 2023 submission.
The video presents the paper “Robo-centric ESDF: A Fast and Accurate Whole-body Collision Evaluation Tool for Any-Shape Robotic Planning”
Paper: ieeexplore.ieee.org/document/10342074
For letting mobile robots travel flexibly through complicated environments, increasing attention has been paid to the whole-body collision evaluation. Most existing works either opt for the conservative corridor-based methods that impose strict requirements on the corridor generation, or ESDF-based methods that suffer from high computational overhead. It is still a great challenge to achieve fast and accurate wholebody collision evaluation. In this paper, we propose a Robocentric ESDF (RC-ESDF) that is pre-built in the robot body frame and is capable of seamlessly applied to any-shape mobile robots, even for those with non-convex shapes. RC-ESDF enjoys lazy collision evaluation, which retains only the minimum information sufficient for whole-body safety constraint and significantly speeds up trajectory optimization. Based on the analytical gradients provided by RC-ESDF, we optimize the position and rotation of robot jointly, with whole-body safety, smoothness, and dynamical feasibility taken into account. Extensive simulation and real-world experiments verified the reliability and generalizability of our method.