Uploaded March 2021 | Updated September 2026, 1 hour ago
Video for the RAL submission.
Preprint: arxiv.org/abs/2103.11178
Code: github.com/ZJU-FAST-Lab/forces_resilient_planner
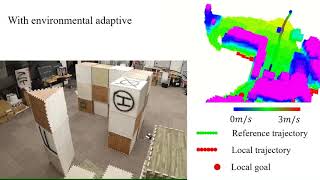
Adaptive autonomous navigation with no prior knowledge of extraneous disturbance is of great significance for quadrotors in a complex and unknown environment. The mainstream that considers external disturbance is to implement disturbance-rejected control and path tracking. However, the robust control to compensate for tracking deviations is not well considered regarding energy consumption, and even the reference path will become risky and intractable with disturbance. As recent external forces estimation advances, it is possible to incorporate a real-time force estimator to develop more robust and safe planning frameworks. This paper proposes a systematic (re)planning framework that can resiliently generate safe trajectories under volatile conditions. Firstly, a frontend kinodynamic path is searched with force-biased motion primitives. Then we develop a nonlinear model predictive control (NMPC) as a local planner with Hamilton-Jacobi (HJ) forward reachability analysis for error dynamics caused by external forces. It guarantees collision-free by constraining the ellipsoid of the quadrotor body expanded with the forward reachable sets (FRSs) within safe convex polytopes. Our method is validated in simulations and real-world experiments with different sources of external forces.
Video for the RAL submission.
Preprint: arxiv.org/abs/2103.11178
Code: github.com/ZJU-FAST-Lab/forces_resilient_planner
Adaptive autonomous navigation with no prior knowledge of extraneous disturbance is of great significance for quadrotors in a complex and unknown environment. The mainstream that considers external disturbance is to implement disturbance-rejected control and path tracking. However, the robust control to compensate for tracking deviations is not well considered regarding energy consumption, and even the reference path will become risky and intractable with disturbance. As recent external forces estimation advances, it is possible to incorporate a real-time force estimator to develop more robust and safe planning frameworks. This paper proposes a systematic (re)planning framework that can resiliently generate safe trajectories under volatile conditions. Firstly, a frontend kinodynamic path is searched with force-biased motion primitives. Then we develop a nonlinear model predictive control (NMPC) as a local planner with Hamilton-Jacobi (HJ) forward reachability analysis for error dynamics caused by external forces. It guarantees collision-free by constraining the ellipsoid of the quadrotor body expanded with the forward reachable sets (FRSs) within safe convex polytopes. Our method is validated in simulations and real-world experiments with different sources of external forces.