Uploaded January 2020 | Updated September 2026, 2 days ago
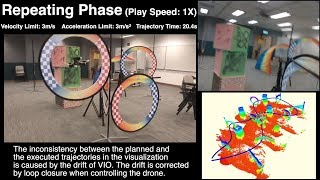
This is a supplementary video of the 'Teach-Repeat-Replan' system. This video shows that our system is insensitive against different levels of manual piloting.
Details about the Teach-Repeat-Replan system can be viewed at:
youtu.be/urEC2AAGEDs
We release all components in our quadrotor system as open-source ros-packages at: https://github.com/HKUST-Aerial-Robot...
The related paper is available at: arxiv.org/abs/1907.00520
This is a supplementary video of the 'Teach-Repeat-Replan' system. This video shows that our system is insensitive against different levels of manual piloting.
Details about the Teach-Repeat-Replan system can be viewed at:
youtu.be/urEC2AAGEDs
We release all components in our quadrotor system as open-source ros-packages at: https://github.com/HKUST-Aerial-Robot...
The related paper is available at: arxiv.org/abs/1907.00520