Uploaded November 2020 | Updated September 2026, 4 hours ago
Video for the ICRA 2021 submission.
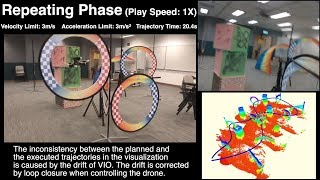
Multicopters are able to perform high maneuverability yet their potential has not been fully achieved. In this work, we propose a full-body, optimization-based motion planning framework that takes the shape and attitude of the aerial robot into consideration such that the aggressiveness of drone maneuvering improves significantly in a cluttered environment. Our method accepts a series of intersecting polyhedrons describing any 3D free spaces and outputs a time-indexed trajectory in real-time with a full-body collision-free fashion. We model the drone as a tilted cuboid, yet we argue that our framework can be freely adjusted to fit aerial vehicles of all shapes. Guarantee-ing dynamic feasibility and safety conditions, our framework transforms the original constrained nonlinear programming problem to an unconstrained one in higher dimensions thus can be approximated by quasi-Newton methods such as LBFGS. Benchmark has shown that our method improves the state-of-art with orders of magnitude in terms of computation time and memory usage. Simulations and onboard experiments are carried out as validation.
Video for the ICRA 2021 submission.
Multicopters are able to perform high maneuverability yet their potential has not been fully achieved. In this work, we propose a full-body, optimization-based motion planning framework that takes the shape and attitude of the aerial robot into consideration such that the aggressiveness of drone maneuvering improves significantly in a cluttered environment. Our method accepts a series of intersecting polyhedrons describing any 3D free spaces and outputs a time-indexed trajectory in real-time with a full-body collision-free fashion. We model the drone as a tilted cuboid, yet we argue that our framework can be freely adjusted to fit aerial vehicles of all shapes. Guarantee-ing dynamic feasibility and safety conditions, our framework transforms the original constrained nonlinear programming problem to an unconstrained one in higher dimensions thus can be approximated by quasi-Newton methods such as LBFGS. Benchmark has shown that our method improves the state-of-art with orders of magnitude in terms of computation time and memory usage. Simulations and onboard experiments are carried out as validation.