Uploaded June 2019 | Updated September 2026, 1 hour ago
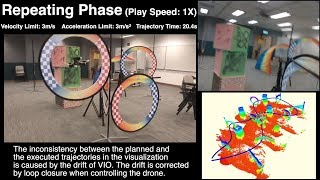
In this paper, we propose a novel and complete motion planning system, 'Teach-Repeat-Replan', for the aggressive flight of autonomous quadrotors.
The proposed method is built upon on a classical teach-and-repeat framework, which is widely adopted in infrastructure inspection, aerial transportation, and search-and-rescue. For these applications, human's intention is essential to decide the topological structure of the flight path of the drone. However, jerky teaching trajectories and changing environments prevent a simple teach-and-repeat system from being applied flexibly and robustly.
In this paper, instead of commanding the drone to precisely follow a teaching trajectory, we propose a method to convert an arbitrarily jerky human-piloted trajectory to a topologically equivalent one, which is guaranteed to be safe, smooth, and kinodynamically feasible with an expected aggressiveness. Also, to avoid unmapped or dynamic obstacles during flights, a sliding-windowed local perception and re-planning method are introduced to our system, to generate safe local trajectories onboard.
We name our system as 'Teach-Repeat-Replan'. It can capture users' intention of a flight mission, convert an arbitrarily jerky teaching path to a smooth repeating trajectory, and generate safe local re-plans to avoid unmapped or moving obstacles. The proposed planning system is integrated into a complete autonomous quadrotor with global and local perception and localization sub-modules.
We release all components in our quadrotor system as open-source ros-packages at: github.com/HKUST-Aerial-Robotics/Teach-Repeat-Replan
Another video shows the application of our proposed system in Electrical and Mechanical Services Department (EMSD), Hong Kong Goverment is available at:
youtu.be/Ut8WT0BURrM
The related paper is available at: arxiv.org/abs/1907.00520
In this paper, we propose a novel and complete motion planning system, 'Teach-Repeat-Replan', for the aggressive flight of autonomous quadrotors.
The proposed method is built upon on a classical teach-and-repeat framework, which is widely adopted in infrastructure inspection, aerial transportation, and search-and-rescue. For these applications, human's intention is essential to decide the topological structure of the flight path of the drone. However, jerky teaching trajectories and changing environments prevent a simple teach-and-repeat system from being applied flexibly and robustly.
In this paper, instead of commanding the drone to precisely follow a teaching trajectory, we propose a method to convert an arbitrarily jerky human-piloted trajectory to a topologically equivalent one, which is guaranteed to be safe, smooth, and kinodynamically feasible with an expected aggressiveness. Also, to avoid unmapped or dynamic obstacles during flights, a sliding-windowed local perception and re-planning method are introduced to our system, to generate safe local trajectories onboard.
We name our system as 'Teach-Repeat-Replan'. It can capture users' intention of a flight mission, convert an arbitrarily jerky teaching path to a smooth repeating trajectory, and generate safe local re-plans to avoid unmapped or moving obstacles. The proposed planning system is integrated into a complete autonomous quadrotor with global and local perception and localization sub-modules.
We release all components in our quadrotor system as open-source ros-packages at: github.com/HKUST-Aerial-Robotics/Teach-Repeat-Replan
Another video shows the application of our proposed system in Electrical and Mechanical Services Department (EMSD), Hong Kong Goverment is available at:
youtu.be/Ut8WT0BURrM
The related paper is available at: arxiv.org/abs/1907.00520