Uploaded September 2021 | Updated September 2026, 45 minutes ago
Video for the RAL submission.
preprint: arxiv.org/abs/2105.10276v3
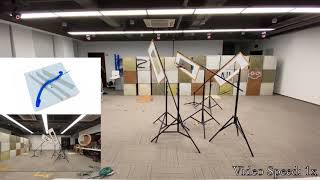
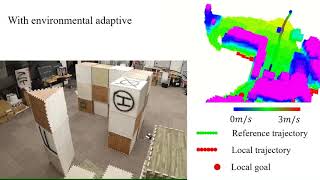
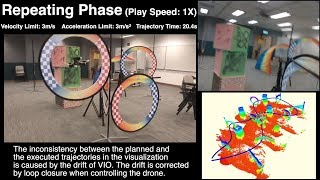
With the autonomy of aerial robots advances in recent years, autonomous drone racing has drawn increasing attention. In a professional pilot competition, a skilled operator always controls the drone to agilely avoid obstacles in aggressive attitudes, for reaching the destination as fast as possible. Autonomous flight like elite pilots requires planning in SE(3), whose non-triviality and complexity hindering a convincing solution in our community by now. To bridge this gap, this paper proposes an open-source baseline, which includes a high-performance SE(3) planner and a challenging simulation platform tailored for drone racing. Firstly, we specify the SE(3) trajectory generation as a soft-penalty optimization problem, and speed up the solving process utilizing its underlying parallel structure. Moreover, to provide a general testbed for challenging the drone racing planner, we develop a set of delicate drone racing tracks which mimic real-world set-up and necessities planning in SE(3). Besides, we provide necessary system components such as common map interfaces and an aggressive baseline controller, to make our work plug-in-and-use. With our baseline, we hope to future foster the research of SE(3) planning and the competition of autonomous drone racing.
Video for the RAL submission.
preprint: arxiv.org/abs/2105.10276v3
With the autonomy of aerial robots advances in recent years, autonomous drone racing has drawn increasing attention. In a professional pilot competition, a skilled operator always controls the drone to agilely avoid obstacles in aggressive attitudes, for reaching the destination as fast as possible. Autonomous flight like elite pilots requires planning in SE(3), whose non-triviality and complexity hindering a convincing solution in our community by now. To bridge this gap, this paper proposes an open-source baseline, which includes a high-performance SE(3) planner and a challenging simulation platform tailored for drone racing. Firstly, we specify the SE(3) trajectory generation as a soft-penalty optimization problem, and speed up the solving process utilizing its underlying parallel structure. Moreover, to provide a general testbed for challenging the drone racing planner, we develop a set of delicate drone racing tracks which mimic real-world set-up and necessities planning in SE(3). Besides, we provide necessary system components such as common map interfaces and an aggressive baseline controller, to make our work plug-in-and-use. With our baseline, we hope to future foster the research of SE(3) planning and the competition of autonomous drone racing.