Uploaded March 2023 | Updated September 2026, 3 minutes ago
The video presents the experimental results of the paper "Automatic Parameter Adaptation for Quadrotor Trajectory Planning" (IROS 2022).
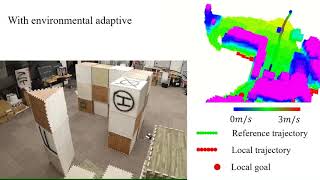
Online trajectory planners enable quadrotors to safely and smoothly navigate in unknown cluttered environments. However, tuning parameters is challenging since modern planners have become too complex to mathematically model and predict their interaction with unstructured environments. This work takes humans out of the loop by proposing a planner parameter adaptation framework that formulates objectives into two complementary categories and optimizes them asynchronously. Objectives evaluated with and without trajectory execution are optimized using Bayesian Optimization (BayesOpt) and Particle Swarm Optimization (PSO), respectively. By combining two kinds of objectives, the total convergence rate of the black-box optimization is accelerated while the dimension of optimized parameters can be increased. Benchmark comparisons demonstrate its superior performance over other strategies. Tests with changing obstacle densities validate its real-time environment adaption, which is difficult for prior manual tuning. Real-world flights with different drone platforms, environments, and planners show the proposed framework's scalability and effectiveness.
The video presents the experimental results of the paper "Automatic Parameter Adaptation for Quadrotor Trajectory Planning" (IROS 2022).
Online trajectory planners enable quadrotors to safely and smoothly navigate in unknown cluttered environments. However, tuning parameters is challenging since modern planners have become too complex to mathematically model and predict their interaction with unstructured environments. This work takes humans out of the loop by proposing a planner parameter adaptation framework that formulates objectives into two complementary categories and optimizes them asynchronously. Objectives evaluated with and without trajectory execution are optimized using Bayesian Optimization (BayesOpt) and Particle Swarm Optimization (PSO), respectively. By combining two kinds of objectives, the total convergence rate of the black-box optimization is accelerated while the dimension of optimized parameters can be increased. Benchmark comparisons demonstrate its superior performance over other strategies. Tests with changing obstacle densities validate its real-time environment adaption, which is difficult for prior manual tuning. Real-world flights with different drone platforms, environments, and planners show the proposed framework's scalability and effectiveness.