Uploaded March 2024 | Updated September 2026, 1 hour ago
Video for the ICRA 2024 submission.
The video presents the paper " Active Collision-Based Navigation for Wheeled Robots".
Preprint:to be released
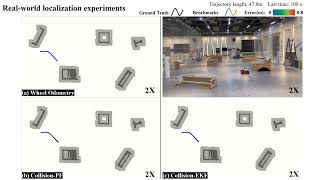
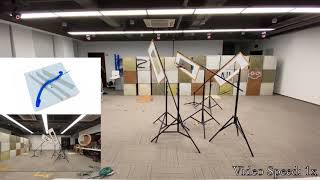
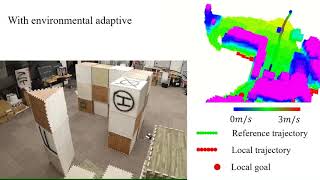
Collision is usually expected to be avoided in robot navigation for safety guarantee. However, when the robot becomes “blind”, which means its exteroceptive sensors fail, collision should be leveraged and we show that it is informative for improving localization performance. Moreover, we show that a robot is able to navigate in a known environment with only proprioceptive sensors by actively colliding in surroundings for more reliable localization. Firstly, we design a collision based observation model, which is differentiable and can be easily applied to various estimators. Secondly, we integrate the proposed model into a collision-aided localization framework and implement it in two typical estimators, Kalman filter and particle filter. Thirdly, we propose an active collision path planning method, which reduces localization uncertainty.
Video for the ICRA 2024 submission.
The video presents the paper " Active Collision-Based Navigation for Wheeled Robots".
Preprint:to be released
Collision is usually expected to be avoided in robot navigation for safety guarantee. However, when the robot becomes “blind”, which means its exteroceptive sensors fail, collision should be leveraged and we show that it is informative for improving localization performance. Moreover, we show that a robot is able to navigate in a known environment with only proprioceptive sensors by actively colliding in surroundings for more reliable localization. Firstly, we design a collision based observation model, which is differentiable and can be easily applied to various estimators. Secondly, we integrate the proposed model into a collision-aided localization framework and implement it in two typical estimators, Kalman filter and particle filter. Thirdly, we propose an active collision path planning method, which reduces localization uncertainty.