Plane Seg on ANYmal (Simulation) @OxfordDynamicRobotSystemsGroup
Plane Seg on ANYmal (Simulation)  @OxfordDynamicRobotSystemsGroup
Uploaded November 2019 | Updated September 2026, 3 weeks ago
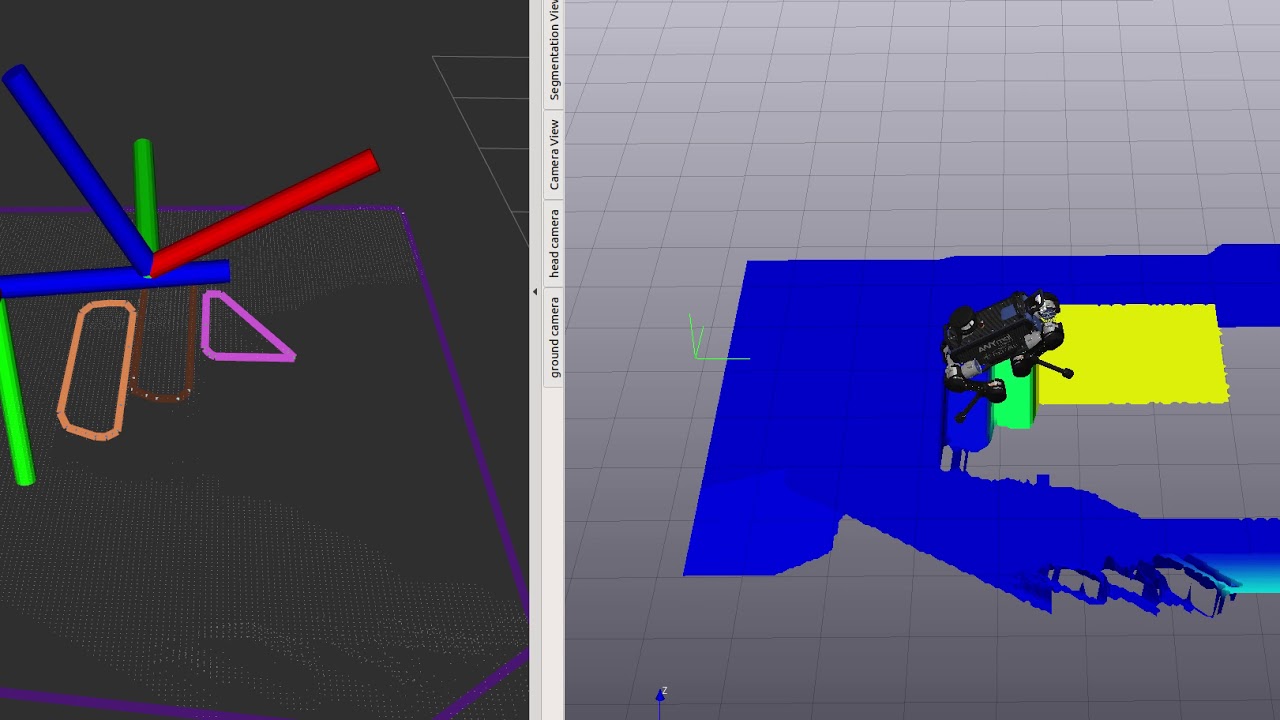
Processing elevation maps to produce convex planes for motion planning. ANYmal is climbing up and down a simulated stair case.

This is the ANYmal Gazebo simulator. In the video ANYmal is using ANYbotic's Locomotion Planner to plan contacts (which doesnt use the plan regions)

Repo:
github.com/ori-drs/plane_seg
Plane Seg on ANYmal (Simulation)RA-L/IROS 2019 - Robust Legged Robot State Estimation Using Factor Graph OptimizationLearning Low-Frequency Motion Control for Robust and Dynamic Robot LocomotionSapling-NeRF: Geo-Localised Sapling Reconstruction in Forests for Ecological MonitoringSafe Visual Navigation in an Underground MineMapping Oxfords Sheldonian TheatreDeep IMU Bias Inference for Robust Visual-Inertial Odometry With Factor Graphs3D Scanning of the Chernobyl Nuclear Power PlantOASIS-Map: Object-Level Change Detection in Multi-Session Mapping using Semantic CorrespondenceScaRF-SLAM: Scale-Consistent Reconstruction via Feed-Forward Models and Classical vSLAMFast Traversability Estimation for Wild Visual NavigationLiSTA: Geometric Object-Based Change Detection in Cluttered Environments
Oxford Dynamic Robot Systems Group |

Plane Seg on ANYmal (Simulation)

SHARE TO X SHARE TO REDDIT SHARE TO FACEBOOK WALLPAPER