Uploaded June 2019 | Updated September 2026, 3 weeks ago
"Robust Legged Robot State Estimation Using Factor Graph Optimization"
David Wisth, Marco Camurri, Maurice Fallon
Paper link: ieeexplore.ieee.org/document/8790726
VILENS website: ori.ox.ac.uk/labs/drs/vilens-tightly-fused-multi-sensor-odometry
Abstract:
Legged robots, specifically quadrupeds, are becom-
ing increasingly attractive for industrial applications such as
inspection. However, to leave the laboratory and to become
useful to an end user requires reliability in harsh conditions.
From the perspective of state estimation, it is essential to be
able to accurately estimate the robot’s state despite challenges
such as uneven or slippery terrain, textureless and reflective
scenes, as well as dynamic camera occlusions. We are motivated
to reduce the dependency on foot contact classifications, which
fail when slipping, and to reduce position drift during dynamic
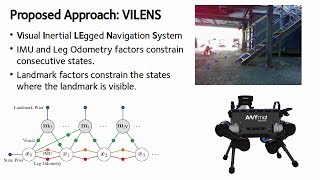
motions such as trotting. To this end, we present a factor
graph optimization method for state estimation which tightly
fuses and smooths inertial navigation, leg odometry and visual
odometry. The effectiveness of the approach is demonstrated
using the ANYmal quadruped robot navigating in a realistic
outdoor industrial environment. This experiment included trotting,
walking, crossing obstacles and ascending a staircase. The
proposed approach decreased the relative position error by up to
55% and absolute position error by 76% compared to kinematic-
inertial odometry.
"Robust Legged Robot State Estimation Using Factor Graph Optimization"
David Wisth, Marco Camurri, Maurice Fallon
Paper link: ieeexplore.ieee.org/document/8790726
VILENS website: ori.ox.ac.uk/labs/drs/vilens-tightly-fused-multi-sensor-odometry
Abstract:
Legged robots, specifically quadrupeds, are becom-
ing increasingly attractive for industrial applications such as
inspection. However, to leave the laboratory and to become
useful to an end user requires reliability in harsh conditions.
From the perspective of state estimation, it is essential to be
able to accurately estimate the robot’s state despite challenges
such as uneven or slippery terrain, textureless and reflective
scenes, as well as dynamic camera occlusions. We are motivated
to reduce the dependency on foot contact classifications, which
fail when slipping, and to reduce position drift during dynamic
motions such as trotting. To this end, we present a factor
graph optimization method for state estimation which tightly
fuses and smooths inertial navigation, leg odometry and visual
odometry. The effectiveness of the approach is demonstrated
using the ANYmal quadruped robot navigating in a realistic
outdoor industrial environment. This experiment included trotting,
walking, crossing obstacles and ascending a staircase. The
proposed approach decreased the relative position error by up to
55% and absolute position error by 76% compared to kinematic-
inertial odometry.