Uploaded November 2021 | Updated September 2026, 3 weeks ago
This video demonstrates some of the results from a scientific deployment to Chernobyl NPP in September 2021 led by University of Bristol.
Our 3D scanning technology was used to build 3D models of various sites with with radiation data (not shown) can be used to monitor the activity levels of remaining nuclear radiation.
More details here:
bristol.ac.uk/news/2021/september/chornobyl-2021.html
This video demonstrates some of the results from a scientific deployment to Chernobyl NPP in September 2021 led by University of Bristol.
Our 3D scanning technology was used to build 3D models of various sites with with radiation data (not shown) can be used to monitor the activity levels of remaining nuclear radiation.
More details here:
bristol.ac.uk/news/2021/september/chornobyl-2021.html
![OASIS-Map: Object-Level Change Detection in Multi-Session Mapping using Semantic Correspondence
[Abstract]
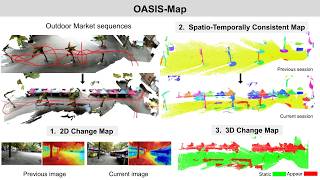
Map representations which are consistent across repeated visits to a real-world semi-static environment are very useful for long-term robotic inspection. In such settings, the scene may evolve while the robot is absent, with objects appearing, disappearing, moving, or being replaced, quickly making a static map outdated. Existing change-detection methods reason through geometry, category-level semantics, or object persistence. However, achieving reliable object association across revisits remains a key challenge, especially under partial views, occlusion, and imperfect segmentation. In this work, we propose OASIS-Map, a multi-session mapping system that maintains a spatio-temporally consistent object-level map by establishing dense patch-level semantic correspondences between temporal observations. These correspondences detect where the scene has changed and incrementally associate objects across revisits as the robot re-observes the environment. We demonstrate OASIS-Map on three challenging real-world scenarios: object rearrangements in 3RScan, visually similar car replacements in a car park, and large-scale scene changes in an outdoor market. We achieve 0.783 F1 on change detection in a car replacement scenario in a car park and 0.667 F1 on moved object association in 3RScan. https://dynamic.robots.ox.ac.uk/projects/oasis-map/
Authors: Haedam Oh, Yifu Tao, Nived Chebrolu, and Maurice Fallon
Pre-print: https://arxiv.org/abs/2607.14899 OASIS-Map: Object-Level Change Detection in Multi-Session Mapping using Semantic Correspondence](https://i.ytimg.com/vi/sfVcFEXyTG4/mqdefault.jpg)