Uploaded July 2026 | Updated September 2026, 3 weeks ago
[Abstract]
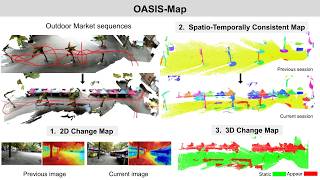
Map representations which are consistent across repeated visits to a real-world semi-static environment are very useful for long-term robotic inspection. In such settings, the scene may evolve while the robot is absent, with objects appearing, disappearing, moving, or being replaced, quickly making a static map outdated. Existing change-detection methods reason through geometry, category-level semantics, or object persistence. However, achieving reliable object association across revisits remains a key challenge, especially under partial views, occlusion, and imperfect segmentation. In this work, we propose OASIS-Map, a multi-session mapping system that maintains a spatio-temporally consistent object-level map by establishing dense patch-level semantic correspondences between temporal observations. These correspondences detect where the scene has changed and incrementally associate objects across revisits as the robot re-observes the environment. We demonstrate OASIS-Map on three challenging real-world scenarios: object rearrangements in 3RScan, visually similar car replacements in a car park, and large-scale scene changes in an outdoor market. We achieve 0.783 F1 on change detection in a car replacement scenario in a car park and 0.667 F1 on moved object association in 3RScan. dynamic.robots.ox.ac.uk/projects/oasis-map
Authors: Haedam Oh, Yifu Tao, Nived Chebrolu, and Maurice Fallon
Pre-print: arxiv.org/abs/2607.14899
[Abstract]
Map representations which are consistent across repeated visits to a real-world semi-static environment are very useful for long-term robotic inspection. In such settings, the scene may evolve while the robot is absent, with objects appearing, disappearing, moving, or being replaced, quickly making a static map outdated. Existing change-detection methods reason through geometry, category-level semantics, or object persistence. However, achieving reliable object association across revisits remains a key challenge, especially under partial views, occlusion, and imperfect segmentation. In this work, we propose OASIS-Map, a multi-session mapping system that maintains a spatio-temporally consistent object-level map by establishing dense patch-level semantic correspondences between temporal observations. These correspondences detect where the scene has changed and incrementally associate objects across revisits as the robot re-observes the environment. We demonstrate OASIS-Map on three challenging real-world scenarios: object rearrangements in 3RScan, visually similar car replacements in a car park, and large-scale scene changes in an outdoor market. We achieve 0.783 F1 on change detection in a car replacement scenario in a car park and 0.667 F1 on moved object association in 3RScan. dynamic.robots.ox.ac.uk/projects/oasis-map
Authors: Haedam Oh, Yifu Tao, Nived Chebrolu, and Maurice Fallon
Pre-print: arxiv.org/abs/2607.14899