Uploaded October 2020 | Updated September 2026, 1 day ago
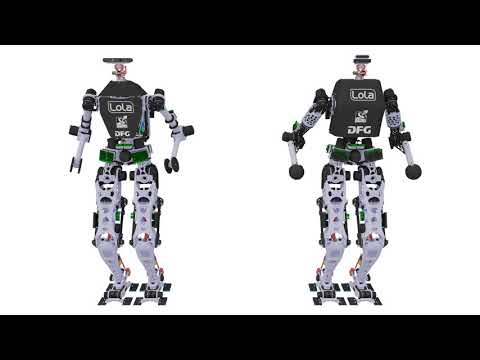
In this video we present recent efforts to make our humanoid robot LOLA ready for multi-contact locomotion, i.e. additional hand-environment support for extra stabilization during walking. We focus on the hardware changes of the upper body (the pelvis and the legs remain unchanged).
Comparison of degrees of freedom (DoFs):
The new upper body features two additional joints, alias "arm rotation", which significantly increase the reachable taskspace. This is essential for supporting against walls in the lateral proximity of the robot.
Assembly:
We explain the composition of the new torso and arm design. The torso contains core components, like the inertial measurement unit (IMU), the two onboard PCs (control and vision), bus couplers and power bridges. Note that the cabling is not modeled and thus not visible in the renderings.
Finite Element Analysis:
A finite element analysis of two exemplary structural parts is shown. These parts have shown to be critical and were developed in an iterative process. The whole robot is designed for minimal weight.
Taskspace Analysis:
The reachable taskspace of the new arm design is compared to the previous topology. We define the torso segment as fixed "base" and the center of the hand as tool center point (TCP). The volume describes the reachable region while the surface is colored according to certain metrics. These metrics indicate "how well" a certain point in 3D space can be reached by the TCP. For this analysis the taskspace is defined as the cartesian position of the TCP relative to the base.
For more information please see our project's website: mw.tum.de/en/am/research/current-projects/robotics/humanoid-robot-lola
This work is supported by the German Research Foundation (DFG, project number 407378162).
In this video we present recent efforts to make our humanoid robot LOLA ready for multi-contact locomotion, i.e. additional hand-environment support for extra stabilization during walking. We focus on the hardware changes of the upper body (the pelvis and the legs remain unchanged).
Comparison of degrees of freedom (DoFs):
The new upper body features two additional joints, alias "arm rotation", which significantly increase the reachable taskspace. This is essential for supporting against walls in the lateral proximity of the robot.
Assembly:
We explain the composition of the new torso and arm design. The torso contains core components, like the inertial measurement unit (IMU), the two onboard PCs (control and vision), bus couplers and power bridges. Note that the cabling is not modeled and thus not visible in the renderings.
Finite Element Analysis:
A finite element analysis of two exemplary structural parts is shown. These parts have shown to be critical and were developed in an iterative process. The whole robot is designed for minimal weight.
Taskspace Analysis:
The reachable taskspace of the new arm design is compared to the previous topology. We define the torso segment as fixed "base" and the center of the hand as tool center point (TCP). The volume describes the reachable region while the surface is colored according to certain metrics. These metrics indicate "how well" a certain point in 3D space can be reached by the TCP. For this analysis the taskspace is defined as the cartesian position of the TCP relative to the base.
For more information please see our project's website: mw.tum.de/en/am/research/current-projects/robotics/humanoid-robot-lola
This work is supported by the German Research Foundation (DFG, project number 407378162).