Uploaded March 2019 | Updated September 2026, 8 hours ago
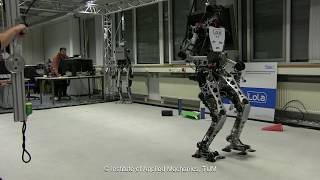
This video shows how the humanoid robot LOLA walks over uneven terrain without using any vision-based information. This reactive robustness to unknown terrain is achieved by a ground-force control scheme that handles ground-height variations and unplanned partial footholds with the environment.
A preprint of the paper describing the force-control scheme is available online:
mediatum.ub.tum.de/doc/1482152/1482152.pdf
An additional video to the development of the force-control scheme is available here: youtu.be/ifuD-ETTi_I
For more information please see our project's website: mw.tum.de/en/am/research/current-projects/robotics/humanoid-robot-lola
This video shows how the humanoid robot LOLA walks over uneven terrain without using any vision-based information. This reactive robustness to unknown terrain is achieved by a ground-force control scheme that handles ground-height variations and unplanned partial footholds with the environment.
A preprint of the paper describing the force-control scheme is available online:
mediatum.ub.tum.de/doc/1482152/1482152.pdf
An additional video to the development of the force-control scheme is available here: youtu.be/ifuD-ETTi_I
For more information please see our project's website: mw.tum.de/en/am/research/current-projects/robotics/humanoid-robot-lola