Simulations of our Humanoid Robot LOLA @AppliedMechanicsTUM
Simulations of our Humanoid Robot LOLA  @AppliedMechanicsTUM
Uploaded March 2015 | Updated September 2026, 12 hours ago
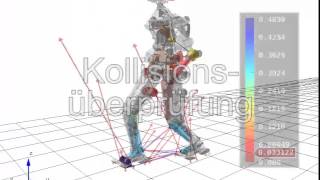
Video showing the simulator of our Humanoid Robot "Lola", including contact forces and collision model. 2010.

Check out our open source repositories!
github.com/am-lola
Simulations of our Humanoid Robot LOLAGyroscope Stability - 1973Humanoid Robot LOLA avoids falling downHumanoid Robot LOLA detects obstacles with a Kinect-like sensor and finds a way around themHumanoid Robot LOLA - Vision Guided Autonomous Multi-Contact LocomotionSmooth Real-Time Walking-Pattern Generation for Humanoid Robot LOLAThe humanoid robot LOLA walks over uneven terrain without using visual informationEfficient Zero-Clamped Cubic Splines Based on Analytical GradientsReal-Time Predictive Kinematic Evaluation and Optimization for Biped RobotsCROPS Manipulator (Generation 1) - Predictive Online Inverse KinematicsALE-Beam Model: Reference/Shifting Motion for a CVTThe Application of Neural Networks for Fidelity Assessment of Real-Time Hybrid Substructuring (RTHS)
TUM Chair of Applied Mechanics |

Simulations of our Humanoid Robot LOLA

SHARE TO X SHARE TO REDDIT SHARE TO FACEBOOK WALLPAPER