Uploaded January 2017 | Updated September 2026, 4 hours ago
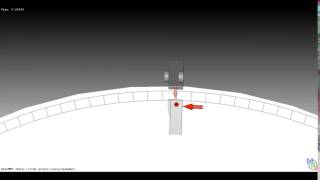
As part of a cooperation with Bosch, our institute has been long working on the simulation and optimization of continuously variable transmissions (CVT). The video shows the spiral running of an element within a pulley groove. Due to the deformation of the pulley-sheaves, the elements effectively changes its running radius along the arc. The video directly results from simulation.
As part of a cooperation with Bosch, our institute has been long working on the simulation and optimization of continuously variable transmissions (CVT). The video shows the spiral running of an element within a pulley groove. Due to the deformation of the pulley-sheaves, the elements effectively changes its running radius along the arc. The video directly results from simulation.