Uploaded October 2026 | Updated November 2026, 1 day ago
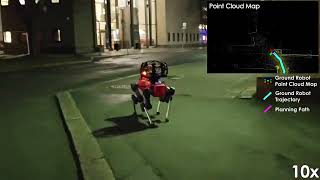
Open-vocabulary 3D maps enable robots to reason about previously unknown environments using natural language. However, existing systems typically segment every incoming image, associate detections with persistent 3D segments, and frequently perform costly Vision-Language (VL) inference. We present TRACKGRAPH, an online open-vocabulary system that maintains short-term 2D mask identity directly in the image stream before fusing segments into 3D. FastSAM masks and CLIP features are computed at sparse keyframes, while dense DINOv3 features are used to propagate masks at a high rate in between. The resulting tracked masks are fused into a class-agnostic 3D segment layer within a hierarchical scene graph, with 3D association handling tracking interruptions and long-term revisits. Compact multi-view CLIP embeddings enable open-vocabulary retrieval. Across Replica, ScanNet++, and HM3D, TRACKGRAPH achieves competitive open-vocabulary segmentation and retrieval against state-of-the-art mapping methods, including the highest synonym frequency on Replica (0.50). On the same NVIDIA A100, it is 1.7x faster and uses 3.3x less GPU memory than ViT-H OVI-MAP. Real-world quadruped deployments demonstrate onboard scene graph construction and object search at 7.5Hz, while recorded drone data is used to test the method under aerial viewpoints.
Project page: ntnu-arl.github.io/trackgraph-site
Code: github.com/ntnu-arl/trackgraph
Open-vocabulary 3D maps enable robots to reason about previously unknown environments using natural language. However, existing systems typically segment every incoming image, associate detections with persistent 3D segments, and frequently perform costly Vision-Language (VL) inference. We present TRACKGRAPH, an online open-vocabulary system that maintains short-term 2D mask identity directly in the image stream before fusing segments into 3D. FastSAM masks and CLIP features are computed at sparse keyframes, while dense DINOv3 features are used to propagate masks at a high rate in between. The resulting tracked masks are fused into a class-agnostic 3D segment layer within a hierarchical scene graph, with 3D association handling tracking interruptions and long-term revisits. Compact multi-view CLIP embeddings enable open-vocabulary retrieval. Across Replica, ScanNet++, and HM3D, TRACKGRAPH achieves competitive open-vocabulary segmentation and retrieval against state-of-the-art mapping methods, including the highest synonym frequency on Replica (0.50). On the same NVIDIA A100, it is 1.7x faster and uses 3.3x less GPU memory than ViT-H OVI-MAP. Real-world quadruped deployments demonstrate onboard scene graph construction and object search at 7.5Hz, while recorded drone data is used to test the method under aerial viewpoints.
Project page: ntnu-arl.github.io/trackgraph-site
Code: github.com/ntnu-arl/trackgraph