Uploaded July 2017 | Updated November 2026, 2 minutes ago
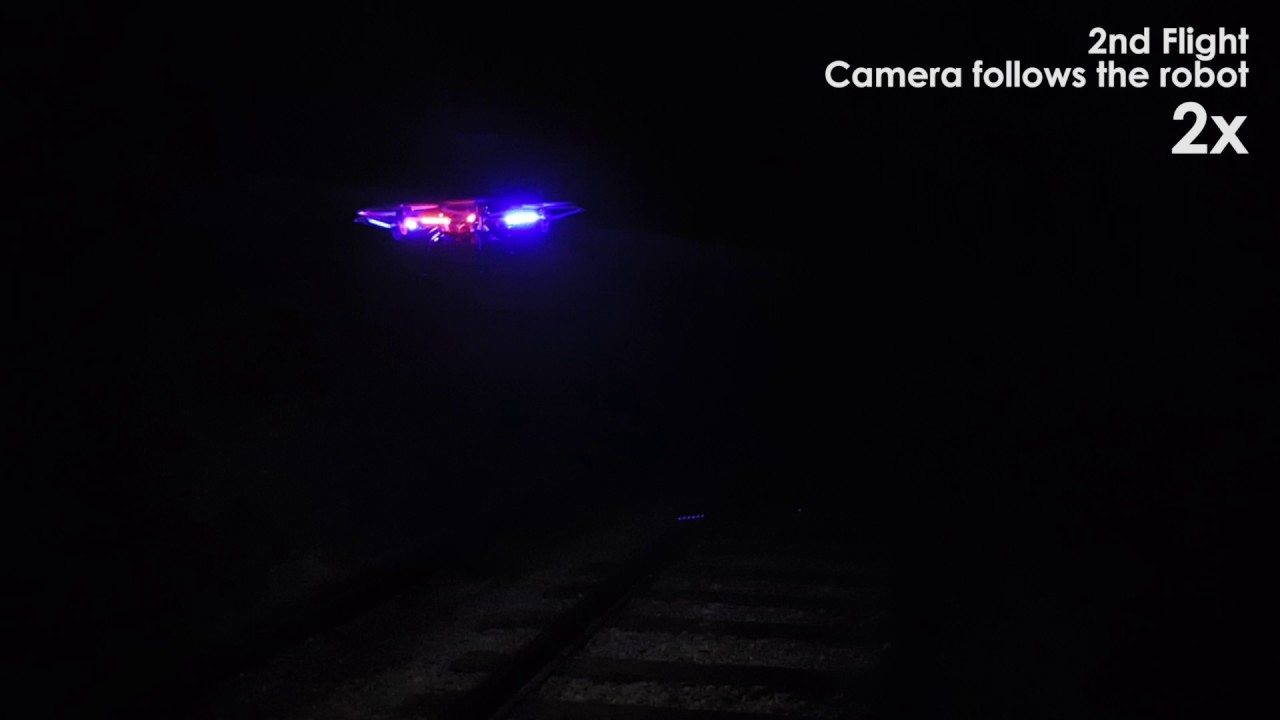
This video presents indicative results of a sequence of field experiments conducted to verify and evaluate new algorithms and systems for autonomous exploration and mapping of tunnel environments using aerial robots. A multitude of such experiments were conducted to verify different algorithms and perception systems.
The Tunnel 4 of V&T Railroad at Virginia City, Nevada was selected for these tests and refers to an approximately 14ft wide, 25ft tall and 450ft long old railway tunnel.
For its autonomous exploration, a small aerial robot equipped with a multi-modal localization and mapping unit, as well as localization uncertainty-aware exploration path planning intelligence was developed and utilized. Given no prior knowledge of its environment, the robot was deployed inside the tunnel and left to explore on its own. The result is a dense map of the tunnel revealing its geometrical and visual characteristics.
In addition, a set of further GPS-denied localization and mapping technologies were tested toward the very high-fidelity mapping of the tunnel from all possible perspectives.
To learn more please visit:
* autonomousrobotslab.com
* github.com/unr-arl/rhem_planner
This video presents indicative results of a sequence of field experiments conducted to verify and evaluate new algorithms and systems for autonomous exploration and mapping of tunnel environments using aerial robots. A multitude of such experiments were conducted to verify different algorithms and perception systems.
The Tunnel 4 of V&T Railroad at Virginia City, Nevada was selected for these tests and refers to an approximately 14ft wide, 25ft tall and 450ft long old railway tunnel.
For its autonomous exploration, a small aerial robot equipped with a multi-modal localization and mapping unit, as well as localization uncertainty-aware exploration path planning intelligence was developed and utilized. Given no prior knowledge of its environment, the robot was deployed inside the tunnel and left to explore on its own. The result is a dense map of the tunnel revealing its geometrical and visual characteristics.
In addition, a set of further GPS-denied localization and mapping technologies were tested toward the very high-fidelity mapping of the tunnel from all possible perspectives.
To learn more please visit:
* autonomousrobotslab.com
* github.com/unr-arl/rhem_planner