Uploaded January 2025 | Updated September 2026, 3 weeks ago
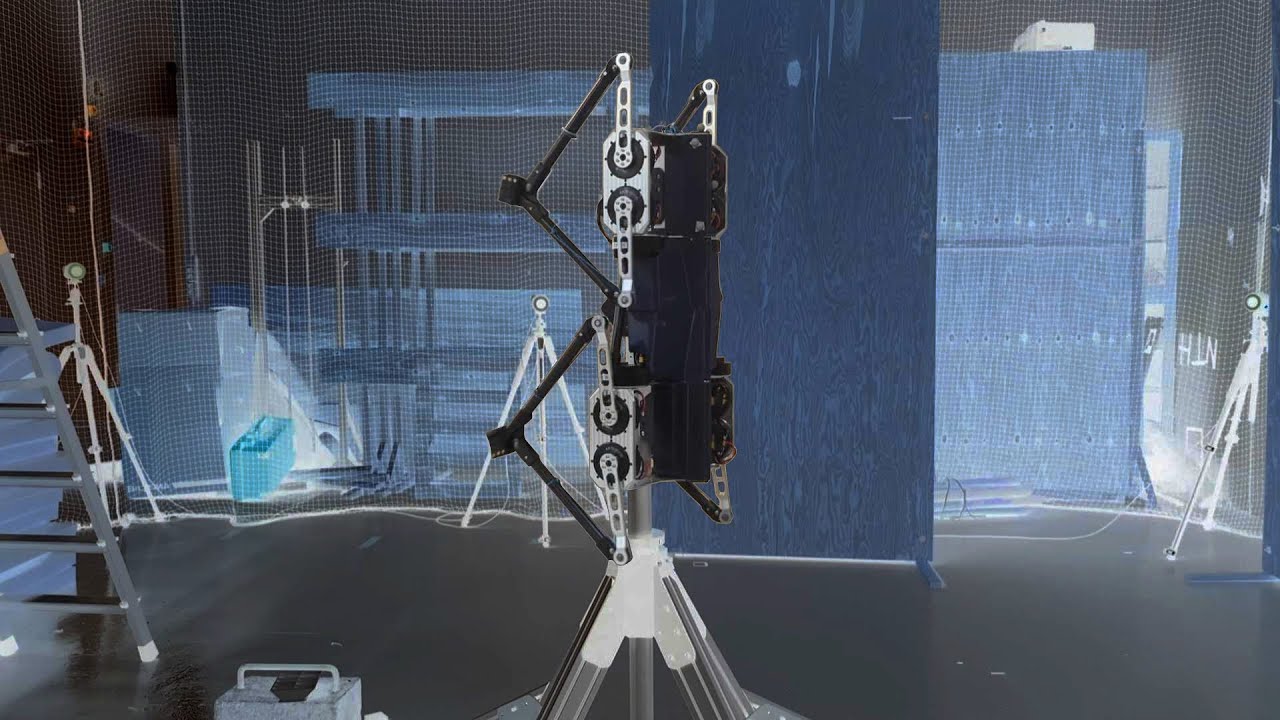
Exploring planetary bodies with lower gravity, such as the moon and Mars, allows legged robots to utilize jumping as an efficient form of locomotion thus giving them a valuable advantage over traditional rovers for exploration. Motivated by this fact, this paper presents the design, simulation, and learning-based "in-flight" attitude control of Olympus, a jumping legged robot tailored to the gravity of Mars. First, the design requirements are outlined followed by detailing how simulation enabled optimizing the robot's design - from its legs to the overall configuration - towards high vertical jumping, forward jumping distance, and in-flight attitude reorientation. Subsequently, the reinforcement learning policy used to track desired in-flight attitude maneuvers is presented. Successfully crossing the sim2real gap, extensive experimental studies of attitude reorientation tests are demonstrated.
Work accepted at IEEE ICRA 2025.
Exploring planetary bodies with lower gravity, such as the moon and Mars, allows legged robots to utilize jumping as an efficient form of locomotion thus giving them a valuable advantage over traditional rovers for exploration. Motivated by this fact, this paper presents the design, simulation, and learning-based "in-flight" attitude control of Olympus, a jumping legged robot tailored to the gravity of Mars. First, the design requirements are outlined followed by detailing how simulation enabled optimizing the robot's design - from its legs to the overall configuration - towards high vertical jumping, forward jumping distance, and in-flight attitude reorientation. Subsequently, the reinforcement learning policy used to track desired in-flight attitude maneuvers is presented. Successfully crossing the sim2real gap, extensive experimental studies of attitude reorientation tests are demonstrated.
Work accepted at IEEE ICRA 2025.