Uploaded May 2018 | Updated September 2026, 1 week ago
ICRA 2018 Spotlight Video
Interactive Session Tue PM Pod E.7
Authors: Elliott, Sarah; Cakmak, Maya
Title: Robotic Cleaning through Dirt Rearrangement Planning with Learned Transition Models
Abstract:
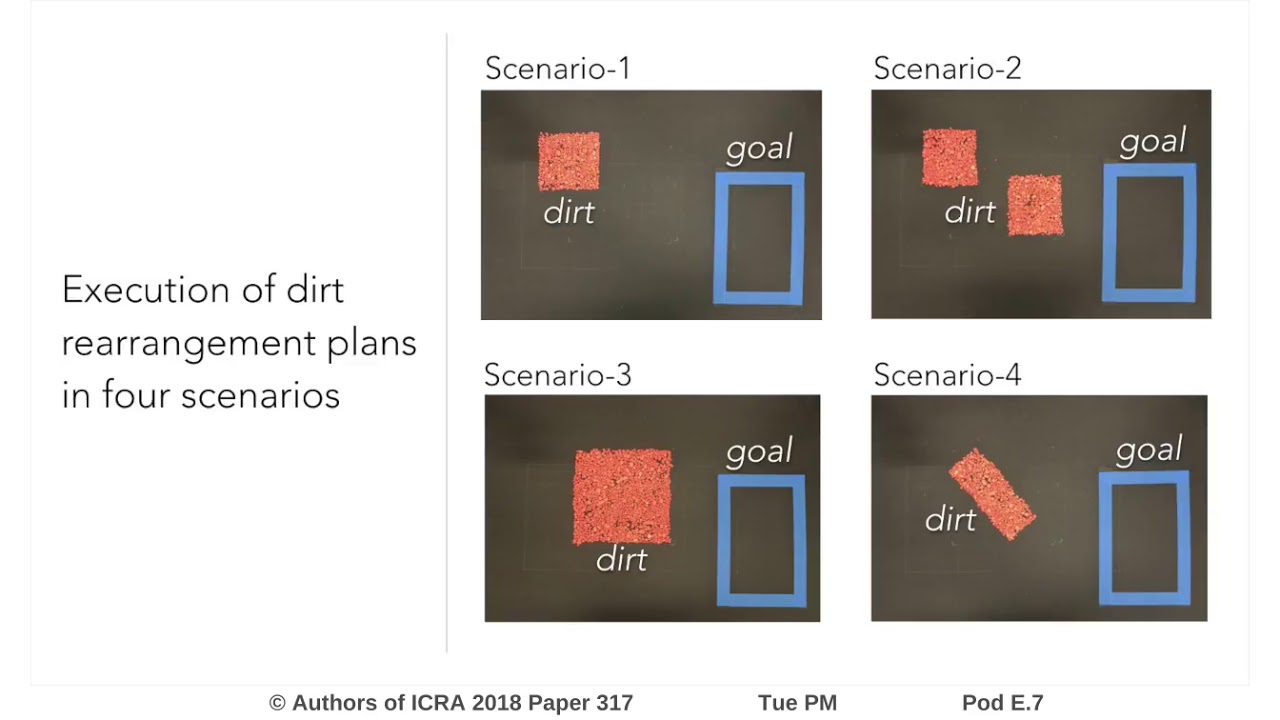
We address the problem of enabling a manipulator to move arbitrary amounts and configurations of dirt on a surface to a goal region using a cleaning tool. We represent this problem as heuristic search with a set of primitive dirt-oriented tool actions. We present dirt and action representations that allow efficient learning and prediction of future dirt states, given the current dirt state and applied action. We also present a method for sampling promising actions based on a clustering of dirt states and heuristics for planning. We demonstrate the effectiveness of our approach on challenging cleaning tasks through implementations on PR2 and Fetch robots.
ICRA 2018 Spotlight Video
Interactive Session Tue PM Pod E.7
Authors: Elliott, Sarah; Cakmak, Maya
Title: Robotic Cleaning through Dirt Rearrangement Planning with Learned Transition Models
Abstract:
We address the problem of enabling a manipulator to move arbitrary amounts and configurations of dirt on a surface to a goal region using a cleaning tool. We represent this problem as heuristic search with a set of primitive dirt-oriented tool actions. We present dirt and action representations that allow efficient learning and prediction of future dirt states, given the current dirt state and applied action. We also present a method for sampling promising actions based on a clustering of dirt states and heuristics for planning. We demonstrate the effectiveness of our approach on challenging cleaning tasks through implementations on PR2 and Fetch robots.