Uploaded May 2018 | Updated September 2026, 1 week ago
ICRA 2018 Spotlight Video
Interactive Session Wed AM Pod A.7
Authors: Hunter, Elizabeth; Brink, Evan; Steager, Edward; Kumar, Vijay
Title: Toward Soft Micro Bio Robots for Cellular and Chemical Delivery
Abstract:
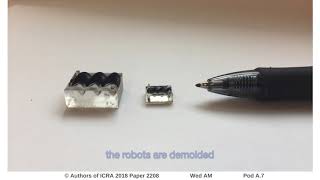
A major driving force propelling the evolution of micrometer and millimeter scale robots is their eventual use in biological environments. Many advancements to microscale robotic technologies have shown that these small scale robots are well-suited for use in environments in which cells and cellular functions require physical manipulation or reprogramming. More specifically, microscale robots are poised for use in the delivery of small molecules, DNA vectors, and proteins which can edit cellular machinery and probe cell signaling systems. In this work, we explore a unique approach to fabricate magnetic millimeter scale robots composed of a biological substrate. We introduce a micromolding fabrication technique in which we manufacture helical structures, which are propelled via uniform rotating magnetic fields. We demonstrate and characterize the swimming capabilities of this robot in media spanning orders of magnitude in viscosities at a range of rotational magnetic field frequencies. Our ability to operate in low Reynolds number environments shows that our system is also relevant to microscale robots. Furthermore, we demonstrate the robot's inherent biocompatibility by establishing our ability to functionalize this robot with living cells and chemicals such that it can be used for biodelivery or to perform on-board biological experiments.
ICRA 2018 Spotlight Video
Interactive Session Wed AM Pod A.7
Authors: Hunter, Elizabeth; Brink, Evan; Steager, Edward; Kumar, Vijay
Title: Toward Soft Micro Bio Robots for Cellular and Chemical Delivery
Abstract:
A major driving force propelling the evolution of micrometer and millimeter scale robots is their eventual use in biological environments. Many advancements to microscale robotic technologies have shown that these small scale robots are well-suited for use in environments in which cells and cellular functions require physical manipulation or reprogramming. More specifically, microscale robots are poised for use in the delivery of small molecules, DNA vectors, and proteins which can edit cellular machinery and probe cell signaling systems. In this work, we explore a unique approach to fabricate magnetic millimeter scale robots composed of a biological substrate. We introduce a micromolding fabrication technique in which we manufacture helical structures, which are propelled via uniform rotating magnetic fields. We demonstrate and characterize the swimming capabilities of this robot in media spanning orders of magnitude in viscosities at a range of rotational magnetic field frequencies. Our ability to operate in low Reynolds number environments shows that our system is also relevant to microscale robots. Furthermore, we demonstrate the robot's inherent biocompatibility by establishing our ability to functionalize this robot with living cells and chemicals such that it can be used for biodelivery or to perform on-board biological experiments.