Uploaded May 2018 | Updated September 2026, 1 week ago
ICRA 2018 Spotlight Video
Interactive Session Wed PM Pod V.4
Authors: McArthur, Daniel; Bhanja Chowdhury, Arindam; Cappelleri, David
Title: Autonomous Control of the Interacting-BoomCopter UAV for Remote Sensor Mounting
Abstract:
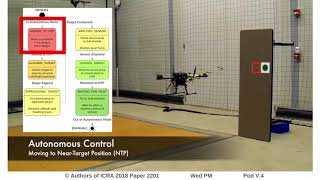
This paper presents a novel approach for autonomously mounting a sensor package on a vertical surface with an unmanned aerial vehicle (UAV). The Interacting-BoomCopter (I-BC) UAV uses an on-board webcam and computer along with a horizontally-mounted reversible propeller on its front boom to autonomously perform the aerial manipulation task. An overview of the vehicle design is presented along with the image processing algorithms used for target tracking, and the implementation of an extended finite state machine (EFSM) for carrying out the high-level autonomous control. The effectiveness of the autonomous control strategy and IBC platform are examined through the performance of several autonomous sensor mounting flight tests.
ICRA 2018 Spotlight Video
Interactive Session Wed PM Pod V.4
Authors: McArthur, Daniel; Bhanja Chowdhury, Arindam; Cappelleri, David
Title: Autonomous Control of the Interacting-BoomCopter UAV for Remote Sensor Mounting
Abstract:
This paper presents a novel approach for autonomously mounting a sensor package on a vertical surface with an unmanned aerial vehicle (UAV). The Interacting-BoomCopter (I-BC) UAV uses an on-board webcam and computer along with a horizontally-mounted reversible propeller on its front boom to autonomously perform the aerial manipulation task. An overview of the vehicle design is presented along with the image processing algorithms used for target tracking, and the implementation of an extended finite state machine (EFSM) for carrying out the high-level autonomous control. The effectiveness of the autonomous control strategy and IBC platform are examined through the performance of several autonomous sensor mounting flight tests.