Uploaded May 2018 | Updated September 2026, 1 week ago
ICRA 2018 Spotlight Video
Interactive Session Thu AM Pod V.6
Authors: Bulka, Eitan; Nahon, Meyer
Title: Autonomous Fixed-Wing Aerobatics: From Theory to Flight
Abstract:
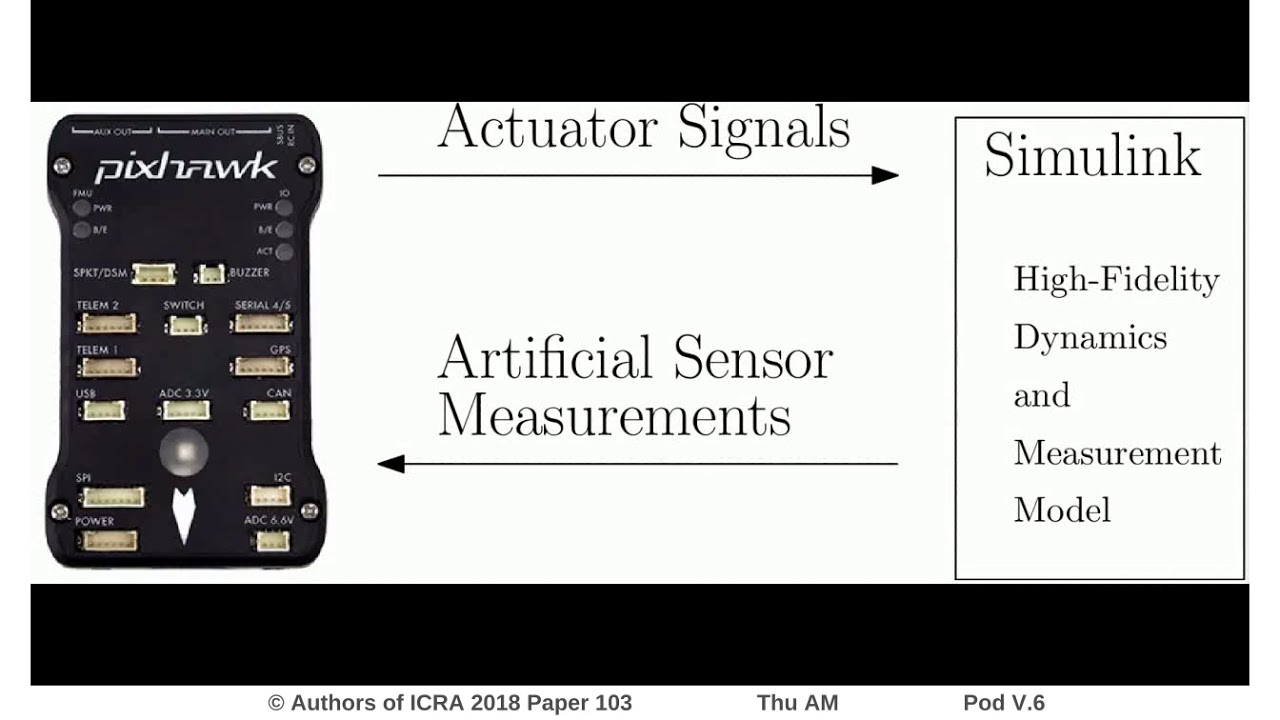
Unmanned aerial vehicles (UAVs) are increasingly being proposed for a wide range of applications. A promising new class of these vehicles, known as agile fixed-wing UAVs, is intended to bridge the gap between conventional fixed-wing aircraft, which can cover long distances efficiently, and rotorcraft, which are typically very maneuverable. This paper addresses the implementation of a controller for agile UAVs, beginning with a hardware-in-the-loop (HIL) simulator, followed by testing on a real platform, both implemented on the Pixhawk microcontroller. We replace the Xplane physics engine used in the standard Pixhawk HIL with our own in-house Matlab/Simulink high-fidelity simulation of an agile UAV. The HIL simulator is found to provide substantial advantages in the transition from pure simulation to experimental testing. Once the controller is integrated into the flight platform, flight tests are conducted, and the results of those tests are compared to those from the HIL simulation and those obtained from the pure simulation environment, for maneuvers including hover, aggressive turnaround, knife-edge, and rolling Harrier. The desired position and orientation time histories were successfully tracked with the proposed implementation, demonstrating the impressive autonomous maneuverability that can be achieved by this type of aircraft.
ICRA 2018 Spotlight Video
Interactive Session Thu AM Pod V.6
Authors: Bulka, Eitan; Nahon, Meyer
Title: Autonomous Fixed-Wing Aerobatics: From Theory to Flight
Abstract:
Unmanned aerial vehicles (UAVs) are increasingly being proposed for a wide range of applications. A promising new class of these vehicles, known as agile fixed-wing UAVs, is intended to bridge the gap between conventional fixed-wing aircraft, which can cover long distances efficiently, and rotorcraft, which are typically very maneuverable. This paper addresses the implementation of a controller for agile UAVs, beginning with a hardware-in-the-loop (HIL) simulator, followed by testing on a real platform, both implemented on the Pixhawk microcontroller. We replace the Xplane physics engine used in the standard Pixhawk HIL with our own in-house Matlab/Simulink high-fidelity simulation of an agile UAV. The HIL simulator is found to provide substantial advantages in the transition from pure simulation to experimental testing. Once the controller is integrated into the flight platform, flight tests are conducted, and the results of those tests are compared to those from the HIL simulation and those obtained from the pure simulation environment, for maneuvers including hover, aggressive turnaround, knife-edge, and rolling Harrier. The desired position and orientation time histories were successfully tracked with the proposed implementation, demonstrating the impressive autonomous maneuverability that can be achieved by this type of aircraft.