Uploaded April 2023 | Updated November 2026, 9 hours ago
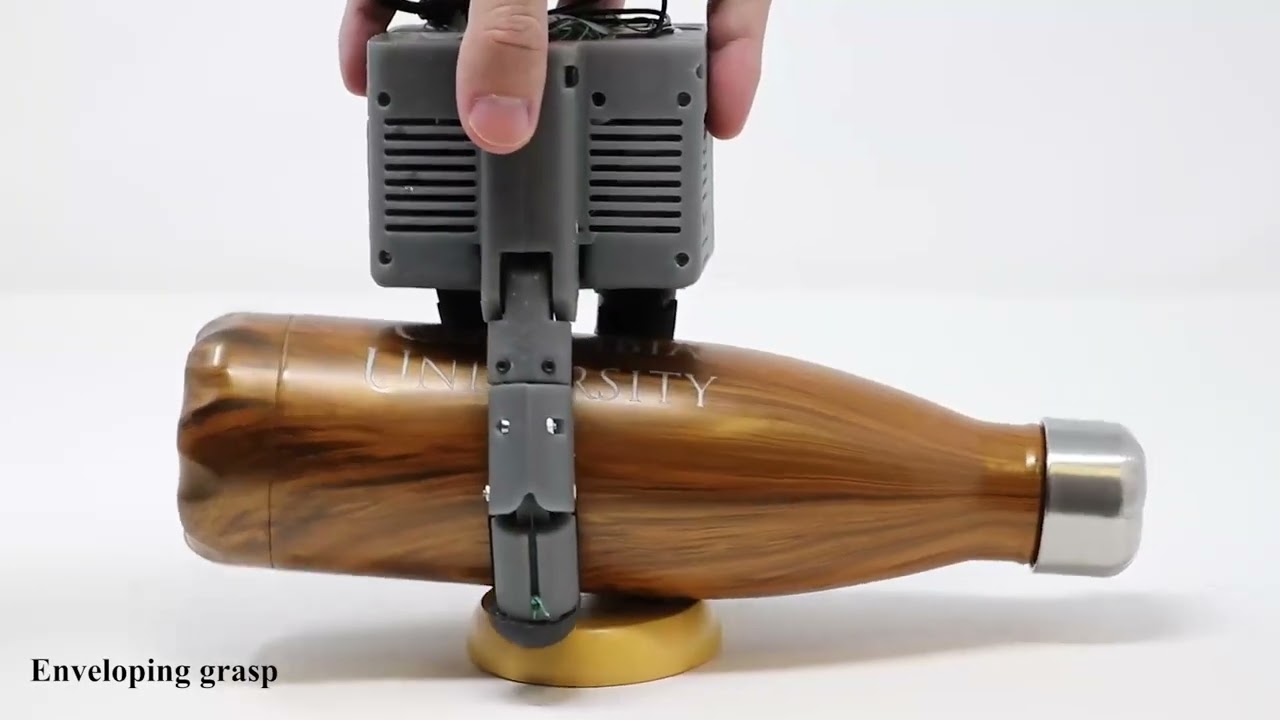
This video is part of the paper "Design Paradigms Based on Spring Agonists for Underactuated Robot Hands: Concepts and Application" by Tianjian Chen, Tianyi Zhang, and Matei Ciocarlie from Columbia University
Presented at the 2021 IEEE International Conference on Robotics and Automation (ICRA)
See the full proceedings: ieeexplore.ieee.org/xpl/conhome/9560720/proceeding
#robot #robotics
This video is part of the paper "Design Paradigms Based on Spring Agonists for Underactuated Robot Hands: Concepts and Application" by Tianjian Chen, Tianyi Zhang, and Matei Ciocarlie from Columbia University
Presented at the 2021 IEEE International Conference on Robotics and Automation (ICRA)
See the full proceedings: ieeexplore.ieee.org/xpl/conhome/9560720/proceeding
#robot #robotics