Uploaded September 2023 | Updated September 2026, 1 week ago
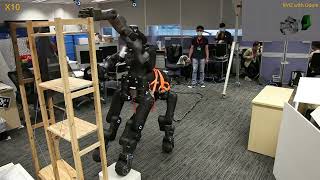
This video is part of the paper "State Estimation for Hybrid Wheeled-Legged Robots Performing Mobile Manipulation Tasks" by Yangwei You, Samuel Cheong, Tai Pang Chen, Yuda Chen, Kun Zhang, Cihan Acar, Fon Lin Lai, Albertus Hendrawan Adiwahono, Keng Peng Tee from Institute for Infocomm Research, Agency for Science, Technology and Research (A*Star), Singapore
Presented at the 2021 IEEE International Conference on Robotics and Automation (ICRA)
See the full proceedings: ieeexplore.ieee.org/xpl/conhome/9560720/proceeding
#robot #robotics
This video is part of the paper "State Estimation for Hybrid Wheeled-Legged Robots Performing Mobile Manipulation Tasks" by Yangwei You, Samuel Cheong, Tai Pang Chen, Yuda Chen, Kun Zhang, Cihan Acar, Fon Lin Lai, Albertus Hendrawan Adiwahono, Keng Peng Tee from Institute for Infocomm Research, Agency for Science, Technology and Research (A*Star), Singapore
Presented at the 2021 IEEE International Conference on Robotics and Automation (ICRA)
See the full proceedings: ieeexplore.ieee.org/xpl/conhome/9560720/proceeding
#robot #robotics