Uploaded May 2018 | Updated September 2026, 2 weeks ago
ICRA 2018 Spotlight Video
Interactive Session Thu PM Pod D.8
Authors: Tosun, Tarik; Daudelin, Jonathan; Jing, Gangyuan; Kress-Gazit, Hadas; Campbell, Mark; Yim, Mark
Title: Perception-Informed Autonomous Environment Augmentation with Modular Robots
Abstract:
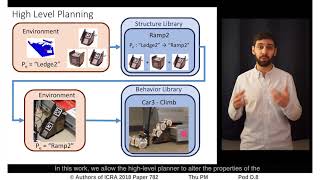
We present a system enabling a modular robot to autonomously build structures in order to accomplish high-level tasks. Building structures allows the robot to surmount large obstacles, expanding the set of tasks it can perform. This addresses a common weakness of modular robot systems, which often struggle to traverse large obstacles. This paper presents the hardware, perception, and planning tools that comprise our system. An environment characterization algorithm identifies features in the environment that can be augmented to create a path between two disconnected regions of the environment. Specially-designed building blocks enable the robot to create structures that can augment the environment to make obstacles traversable. A high-level planner reasons about the task, robot locomotion capabilities, and environment to decide if and where to augment the environment in order to perform the desired task. We validate our system in hardware experiments.
ICRA 2018 Spotlight Video
Interactive Session Thu PM Pod D.8
Authors: Tosun, Tarik; Daudelin, Jonathan; Jing, Gangyuan; Kress-Gazit, Hadas; Campbell, Mark; Yim, Mark
Title: Perception-Informed Autonomous Environment Augmentation with Modular Robots
Abstract:
We present a system enabling a modular robot to autonomously build structures in order to accomplish high-level tasks. Building structures allows the robot to surmount large obstacles, expanding the set of tasks it can perform. This addresses a common weakness of modular robot systems, which often struggle to traverse large obstacles. This paper presents the hardware, perception, and planning tools that comprise our system. An environment characterization algorithm identifies features in the environment that can be augmented to create a path between two disconnected regions of the environment. Specially-designed building blocks enable the robot to create structures that can augment the environment to make obstacles traversable. A high-level planner reasons about the task, robot locomotion capabilities, and environment to decide if and where to augment the environment in order to perform the desired task. We validate our system in hardware experiments.