Uploaded May 2018 | Updated September 2026, 2 weeks ago
ICRA 2018 Spotlight Video
Interactive Session Tue AM Pod M.8
Authors: Yang, Huaiguang; Ding, Liang; Gao, Haibo; Huang, Lan; GUO, Junlong; Chen, Chao; Deng, Zongquan
Title: Dynamic Simulation of Planetary Rovers with Terrain Property Mapping
Abstract:
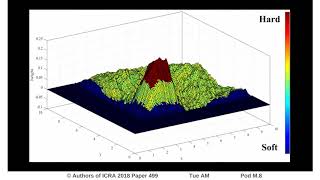
Simulation of planetary rovers moving on complex terrains is critical for Mars exploration. Equivalent stiffness is proposed and used to characterize the pressure-sinkage property of terrain, while friction angle to characterize the shearing property. Terramechanics model for calculating forces between rigid wheel and soil is proved to be the same with that contact model for calculating forces between rigid wheel and rock. A Digital Elevation Map with Physical Properties is developed and applied to simulate terrain physical properties along with its geometry information. The established methods are validated using simulation and experimental tests with a three-wheel-rover.
ICRA 2018 Spotlight Video
Interactive Session Tue AM Pod M.8
Authors: Yang, Huaiguang; Ding, Liang; Gao, Haibo; Huang, Lan; GUO, Junlong; Chen, Chao; Deng, Zongquan
Title: Dynamic Simulation of Planetary Rovers with Terrain Property Mapping
Abstract:
Simulation of planetary rovers moving on complex terrains is critical for Mars exploration. Equivalent stiffness is proposed and used to characterize the pressure-sinkage property of terrain, while friction angle to characterize the shearing property. Terramechanics model for calculating forces between rigid wheel and soil is proved to be the same with that contact model for calculating forces between rigid wheel and rock. A Digital Elevation Map with Physical Properties is developed and applied to simulate terrain physical properties along with its geometry information. The established methods are validated using simulation and experimental tests with a three-wheel-rover.