Uploaded May 2018 | Updated September 2026, 2 weeks ago
ICRA 2018 Spotlight Video
Interactive Session Thu PM Pod M.5
Authors: Cho, Kyunghoon; Oh, Songhwai
Title: Learning-Based Model Predictive Control under Signal Temporal Logic Specifications
Abstract:
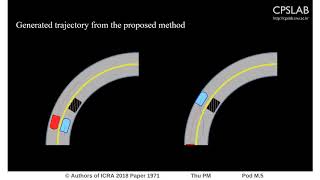
This paper presents a control strategy synthesis method for dynamical systems with differential constraints while satisfying a set of given rules in consideration of their importances. A special attention is given to situations where all rules cannot be met in order to fulfill a given task. Such dilemmas compel us to make a decision on the degree of satisfaction of each rule including which rule should be maintained or not. In this work, we propose a learning based model predictive control method in order to solve this problem, where a key insight is to combine a learning method and traditional control scheme so that the designed controller behaves close to human experts. A rule is represented as a signal temporal logic (STL) formula. A robustness slackness, a margin to the satisfaction of the rule, is learned from experts demonstrations using Gaussian process regression. The learned margin is used in a model predictive control procedure, which helps to decide how much to obey each rule, even ignoring specific rules. In track driving simulation, we show that the proposed method generates human-like behavior and efficiently handles dilemmas as human teachers do.
ICRA 2018 Spotlight Video
Interactive Session Thu PM Pod M.5
Authors: Cho, Kyunghoon; Oh, Songhwai
Title: Learning-Based Model Predictive Control under Signal Temporal Logic Specifications
Abstract:
This paper presents a control strategy synthesis method for dynamical systems with differential constraints while satisfying a set of given rules in consideration of their importances. A special attention is given to situations where all rules cannot be met in order to fulfill a given task. Such dilemmas compel us to make a decision on the degree of satisfaction of each rule including which rule should be maintained or not. In this work, we propose a learning based model predictive control method in order to solve this problem, where a key insight is to combine a learning method and traditional control scheme so that the designed controller behaves close to human experts. A rule is represented as a signal temporal logic (STL) formula. A robustness slackness, a margin to the satisfaction of the rule, is learned from experts demonstrations using Gaussian process regression. The learned margin is used in a model predictive control procedure, which helps to decide how much to obey each rule, even ignoring specific rules. In track driving simulation, we show that the proposed method generates human-like behavior and efficiently handles dilemmas as human teachers do.