Uploaded May 2018 | Updated September 2026, 2 weeks ago
ICRA 2018 Spotlight Video
Interactive Session Tue PM Pod Q.4
Authors: Horigome, Atsushi; Endo, Gen
Title: Investigation of Repetitive Bending Durability of Synthetic Fiber Ropes
Abstract:
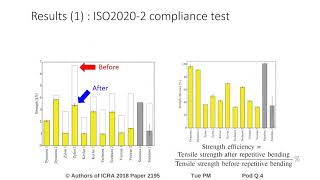
A synthetic fiber rope, which is lightweight and has a high tensile strength and flexibility, is receiving much attention as a replacement for a stainless steel wire rope. This paper describes its ability to endure repetitive bending. We performed experiments in conformity with the ISO 2020-2 standard using ten synthetic fiber ropes made of different materials and with different compositions, along with two stainless steel wire ropes. As a result, a 7x19 stainless steel wire rope and an ultra-high molecular weight polyethylene rope (SK-71), which has a high resistance to frictional wear, did not experience significant loss of tensile strength. However, repeated bending caused the tensile strength deterioration of the other synthetic fiber ropes, which had low resistances to frictional wear. In the case of steep bending with a small pulley or bending with high tension, we experimentally revealed that some synthetic fiber ropes are superior to stainless steel wire ropes.
ICRA 2018 Spotlight Video
Interactive Session Tue PM Pod Q.4
Authors: Horigome, Atsushi; Endo, Gen
Title: Investigation of Repetitive Bending Durability of Synthetic Fiber Ropes
Abstract:
A synthetic fiber rope, which is lightweight and has a high tensile strength and flexibility, is receiving much attention as a replacement for a stainless steel wire rope. This paper describes its ability to endure repetitive bending. We performed experiments in conformity with the ISO 2020-2 standard using ten synthetic fiber ropes made of different materials and with different compositions, along with two stainless steel wire ropes. As a result, a 7x19 stainless steel wire rope and an ultra-high molecular weight polyethylene rope (SK-71), which has a high resistance to frictional wear, did not experience significant loss of tensile strength. However, repeated bending caused the tensile strength deterioration of the other synthetic fiber ropes, which had low resistances to frictional wear. In the case of steep bending with a small pulley or bending with high tension, we experimentally revealed that some synthetic fiber ropes are superior to stainless steel wire ropes.