Uploaded May 2018 | Updated September 2026, 2 weeks ago
ICRA 2018 Spotlight Video
Interactive Session Thu PM Pod H.8
Authors: Huang, Chong; Gao, Fei; Pan, Jie; Yang, Zhenyu; Qiu, Weihao; Chen, Peng; Yang, Xin; Shen, Shaojie; Cheng, Kwang-Ting (Tim)
Title: ACT: An Autonomous Drone Cinematography System for Action Scenes
Abstract:
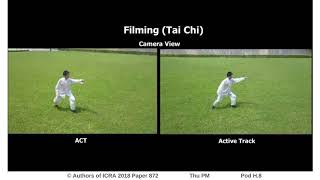
Drones are enabling new forms of cinematography. Aerial filming via drones in action scenes is difficult because it requires users to understand the dynamic scenarios and operate the drone and camera simultaneously. Existing systems allow the user to manually specify the shots and guide the drone to capture footage, while none of them employ aesthetic objectives to automate aerial filming in action scenes. Meanwhile, these drone cinematography systems depend on the external motion capture systems to perceive the human action, which is limited to the indoor environment. To address the above challenges, we propose an Autonomous CinemaTography system "ACT" on the drone platform, which can autonomously capture cinematic shots based on limb movements in both indoor and outdoor environments. Our system includes the following novelties. First, we propose an efficient method to extract 3D skeleton points via a stereo camera. Second, we design a real-time dynamical camera planning strategy that fulfills the aesthetic objectives for filming and respects the physical limits of a drone. At the system level, we integrate cameras and GPUs into the limited space of a drone and demonstrate the feasibility of running the entire cinematography system onboard in real-time. Experimental results in both simulation and real-world scenarios demonstrate that our proposed ACT system can capture more expressive footage of human action than that of the state-of-the-art drone camera system.
ICRA 2018 Spotlight Video
Interactive Session Thu PM Pod H.8
Authors: Huang, Chong; Gao, Fei; Pan, Jie; Yang, Zhenyu; Qiu, Weihao; Chen, Peng; Yang, Xin; Shen, Shaojie; Cheng, Kwang-Ting (Tim)
Title: ACT: An Autonomous Drone Cinematography System for Action Scenes
Abstract:
Drones are enabling new forms of cinematography. Aerial filming via drones in action scenes is difficult because it requires users to understand the dynamic scenarios and operate the drone and camera simultaneously. Existing systems allow the user to manually specify the shots and guide the drone to capture footage, while none of them employ aesthetic objectives to automate aerial filming in action scenes. Meanwhile, these drone cinematography systems depend on the external motion capture systems to perceive the human action, which is limited to the indoor environment. To address the above challenges, we propose an Autonomous CinemaTography system "ACT" on the drone platform, which can autonomously capture cinematic shots based on limb movements in both indoor and outdoor environments. Our system includes the following novelties. First, we propose an efficient method to extract 3D skeleton points via a stereo camera. Second, we design a real-time dynamical camera planning strategy that fulfills the aesthetic objectives for filming and respects the physical limits of a drone. At the system level, we integrate cameras and GPUs into the limited space of a drone and demonstrate the feasibility of running the entire cinematography system onboard in real-time. Experimental results in both simulation and real-world scenarios demonstrate that our proposed ACT system can capture more expressive footage of human action than that of the state-of-the-art drone camera system.