Uploaded May 2018 | Updated September 2026, 2 weeks ago
ICRA 2018 Spotlight Video
Interactive Session Thu AM Pod F.2
Authors: Mullins, Galen; Stankiewicz, Paul; Appler, Jordan; Dress, Austin; Gupta, Satyandra K.
Title: Accelerated Testing and Evaluation of Autonomous Vehicles Via Imitation Learning
Abstract:
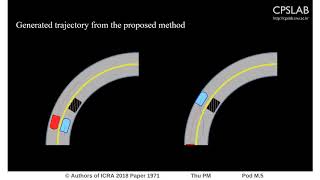
In this paper, we investigate the use of surrogate agents to accelerate test scenario generation for autonomous vehicles. Our goal is to train the surrogate to replicate the true performance modes of the system. We create these surrogates by utilizing imitation learning with deep neural networks. By using imitator surrogates in place of the true agent, we are capable of predicting mission performance more quickly, gaining greater throughput for simulation-based testing. We demonstrate that using on-line imitation learning with Dataset Aggregation (DAgger) can not only correctly encode a policy that executes a complex mission, but can also encode multiple different behavioral modes. To improve performance for the target vehicle and mission, we manipulate the training set during each iteration to remove samples which do not contribute to the final policy. We call this approach Quantile-DAgger (Q-DAgger) and demonstrate its ability to replicate the behaviors of an autonomous vehicle in a collision avoidance scenario.
ICRA 2018 Spotlight Video
Interactive Session Thu AM Pod F.2
Authors: Mullins, Galen; Stankiewicz, Paul; Appler, Jordan; Dress, Austin; Gupta, Satyandra K.
Title: Accelerated Testing and Evaluation of Autonomous Vehicles Via Imitation Learning
Abstract:
In this paper, we investigate the use of surrogate agents to accelerate test scenario generation for autonomous vehicles. Our goal is to train the surrogate to replicate the true performance modes of the system. We create these surrogates by utilizing imitation learning with deep neural networks. By using imitator surrogates in place of the true agent, we are capable of predicting mission performance more quickly, gaining greater throughput for simulation-based testing. We demonstrate that using on-line imitation learning with Dataset Aggregation (DAgger) can not only correctly encode a policy that executes a complex mission, but can also encode multiple different behavioral modes. To improve performance for the target vehicle and mission, we manipulate the training set during each iteration to remove samples which do not contribute to the final policy. We call this approach Quantile-DAgger (Q-DAgger) and demonstrate its ability to replicate the behaviors of an autonomous vehicle in a collision avoidance scenario.