Uploaded May 2018 | Updated September 2026, 2 weeks ago
ICRA 2018 Spotlight Video
Interactive Session Tue PM Pod D.1
Authors: Thompson, Nicholas; Zhang, Xiaotian; Ayala, Fernando; Hsiao-Wecksler, Elizabeth; Krishnan, Girish
Title: Augmented Joint Stiffness and Actuation Using Architectures of Soft Pneumatic Actuators
Abstract:
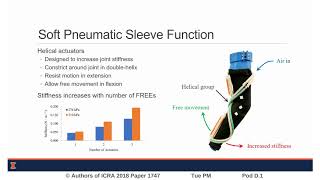
Soft robotic actuators are well suited for use in exoskeleton applications due to their innate compliance and low weight . We have developed a wearable soft robotic sleeve that uses fiber reinforced elastomeric enclosures (FREEs) to provide actuation and stiffness at the elbow for augmented lifting and carrying ability. The sleeve includes novel linear and helical actuator architectures to induce and resist joint movement respectively, and is intended to be comfortable, lightweight, and low profile. We developed test protocols to measure actuation and stiffness performance of different helical and linear architectures, and to compare helical and linear actuator groups when used individually and together. Our findings indicate that nested linear actuators have superior contraction ratios compared to parallel linear actuators, resulting in greater angular displacement. Stiffness from helical actuators increased with pressure and number of parallel actuators. A combined linear-helical actuator configuration considerably outperformed helical and linear actuator groups when used on their own.
ICRA 2018 Spotlight Video
Interactive Session Tue PM Pod D.1
Authors: Thompson, Nicholas; Zhang, Xiaotian; Ayala, Fernando; Hsiao-Wecksler, Elizabeth; Krishnan, Girish
Title: Augmented Joint Stiffness and Actuation Using Architectures of Soft Pneumatic Actuators
Abstract:
Soft robotic actuators are well suited for use in exoskeleton applications due to their innate compliance and low weight . We have developed a wearable soft robotic sleeve that uses fiber reinforced elastomeric enclosures (FREEs) to provide actuation and stiffness at the elbow for augmented lifting and carrying ability. The sleeve includes novel linear and helical actuator architectures to induce and resist joint movement respectively, and is intended to be comfortable, lightweight, and low profile. We developed test protocols to measure actuation and stiffness performance of different helical and linear architectures, and to compare helical and linear actuator groups when used individually and together. Our findings indicate that nested linear actuators have superior contraction ratios compared to parallel linear actuators, resulting in greater angular displacement. Stiffness from helical actuators increased with pressure and number of parallel actuators. A combined linear-helical actuator configuration considerably outperformed helical and linear actuator groups when used on their own.