Uploaded September 2011 | Updated September 2026, 1 week ago
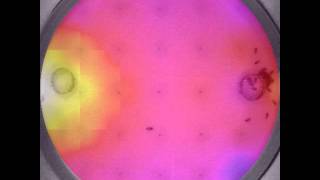
In this video we tested our newly developed color-sensing add-on board for the ePuck educational robot (www.e-puck.org). On impact with an obstacle the robot discriminates between walls and other robots. When another robot is detected it waits a certain amount of time. The amount of time it waits is determined by the current brightness in the arena. This leads to an aggregation in the brightest spot of the arena and represents the BEECLUST algorithm developed in our lab (http://zool33.uni-graz.at/artlife/node/164), which in turn was inspired from the aggregation behaviour of young honeybees in temperature gradients.
Video by Ralf Mayet & Thomas Kunzfeld.
For more information please see http://zool33.uni-graz.at/artlife or contact Thomas Schmickl at (thomas.schmickl@uni-graz.at).
In this video we tested our newly developed color-sensing add-on board for the ePuck educational robot (www.e-puck.org). On impact with an obstacle the robot discriminates between walls and other robots. When another robot is detected it waits a certain amount of time. The amount of time it waits is determined by the current brightness in the arena. This leads to an aggregation in the brightest spot of the arena and represents the BEECLUST algorithm developed in our lab (http://zool33.uni-graz.at/artlife/node/164), which in turn was inspired from the aggregation behaviour of young honeybees in temperature gradients.
Video by Ralf Mayet & Thomas Kunzfeld.
For more information please see http://zool33.uni-graz.at/artlife or contact Thomas Schmickl at (thomas.schmickl@uni-graz.at).