Uploaded June 2015 | Updated September 2026, 1 week ago
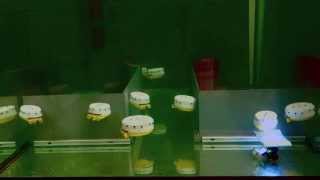
The Year of CoCoRo 24/52: This video shows Jeff robots in searching a structured, highly fragmented habitat. The important issue here is the area coverage that can be achieved by the autonomous motion behavior. We found that a simple program called "correlated random walk with obstacle avoidance" does the job quite well. This program is straight forward motion altered by infrequent randomly triggered random turns and collision avoidance based on blue-light emissions and reflection at the nose of the robot. One robot covers the habitat already quickly, more robots even faster. This scalability is important to generate a useful robot swarm.
The Year of CoCoRo 24/52: This video shows Jeff robots in searching a structured, highly fragmented habitat. The important issue here is the area coverage that can be achieved by the autonomous motion behavior. We found that a simple program called "correlated random walk with obstacle avoidance" does the job quite well. This program is straight forward motion altered by infrequent randomly triggered random turns and collision avoidance based on blue-light emissions and reflection at the nose of the robot. One robot covers the habitat already quickly, more robots even faster. This scalability is important to generate a useful robot swarm.