Uploaded November 2015 | Updated September 2026, 1 week ago
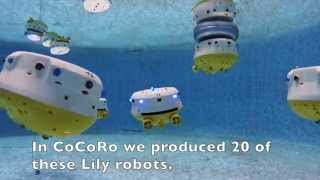
The Year of CoCoRo 44/52: For a swarm it is crucial that the robots stay together. One method is to generate a "virtual fence" around the swarm, as we already demonstrated it with various "confinement" videos in the Year of CoCoRo (weeks 17-19). Besides those methods it is also nice if the robots stay together like a school of fish, a flock of birds or a swarm of mosquitos would do it. We wanted to mimic those simple individual behaviors that produce collectively a coherent global swarming behavior. Our Lily robots look at blinking blue-light signals form neighboring robots. Based on the estimated distance between the robots they decide with a simple threshold-based mechanisms in which direction to turn and how to adjust their motion speed. Although this system is very simple it nicely allows the robots to stay together for longer periods of time.
The Year of CoCoRo 44/52: For a swarm it is crucial that the robots stay together. One method is to generate a "virtual fence" around the swarm, as we already demonstrated it with various "confinement" videos in the Year of CoCoRo (weeks 17-19). Besides those methods it is also nice if the robots stay together like a school of fish, a flock of birds or a swarm of mosquitos would do it. We wanted to mimic those simple individual behaviors that produce collectively a coherent global swarming behavior. Our Lily robots look at blinking blue-light signals form neighboring robots. Based on the estimated distance between the robots they decide with a simple threshold-based mechanisms in which direction to turn and how to adjust their motion speed. Although this system is very simple it nicely allows the robots to stay together for longer periods of time.