Uploaded August 2015 | Updated September 2026, 1 week ago
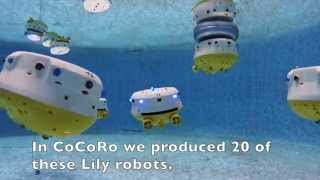
The Year of CoCoRo 34/52: This video shows a series of experiments we performed on the building and persistency of the relay chain, which is a chain of Lily robots that connects two spatially separated points in the underwater habitat. In the first set of experiments these two end points are fixed, while in the second set of experiments they are moving, thus the relay chain formed by the robot swarm has to reconfigure and reshape. The robots forming the chain perform an algorithm inspired by the shoaling behavior of fish. They look out for blue-light blinks of neighboring robots with their photoreceptors (photodiodes). From the light intensity that falls into those sensors they infer very roughly the distance and angle of those neighbors. Based on these pieces of information they decide into which direction they turn and move. Although the mechanism involves blinking signals the algorithm can work "communication free", as an onboard camera and image processing can replace this sensing and then no signal has to be send from neighboring AUVs. Thus it can also operate on passive sensing, what is important for the scalability of the method.
The Year of CoCoRo 34/52: This video shows a series of experiments we performed on the building and persistency of the relay chain, which is a chain of Lily robots that connects two spatially separated points in the underwater habitat. In the first set of experiments these two end points are fixed, while in the second set of experiments they are moving, thus the relay chain formed by the robot swarm has to reconfigure and reshape. The robots forming the chain perform an algorithm inspired by the shoaling behavior of fish. They look out for blue-light blinks of neighboring robots with their photoreceptors (photodiodes). From the light intensity that falls into those sensors they infer very roughly the distance and angle of those neighbors. Based on these pieces of information they decide into which direction they turn and move. Although the mechanism involves blinking signals the algorithm can work "communication free", as an onboard camera and image processing can replace this sensing and then no signal has to be send from neighboring AUVs. Thus it can also operate on passive sensing, what is important for the scalability of the method.