Uploaded September 2011 | Updated September 2026, 1 week ago
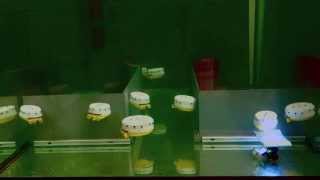
In this video we present our first tests on robot-to-robot collision detection with the ePuck educational robot (www.e-puck.org). To discriminate obstacles (such as the walls of the arena) from robots, each ePuck sends out encoded infrared packages that are detected when a potential obstacle is encountered. In this test the robots turn in a circle and switch on their LEDs when another robot is encountered. When a wall is detected the robot turns and drives in the other direction.
Video by Ralf Mayet & Thomas Kunzfeld.
For more information please see http://zool33.uni-graz.at/artlife or contact Thomas Schmickl at (thomas.schmickl@uni-graz.at).
In this video we present our first tests on robot-to-robot collision detection with the ePuck educational robot (www.e-puck.org). To discriminate obstacles (such as the walls of the arena) from robots, each ePuck sends out encoded infrared packages that are detected when a potential obstacle is encountered. In this test the robots turn in a circle and switch on their LEDs when another robot is encountered. When a wall is detected the robot turns and drives in the other direction.
Video by Ralf Mayet & Thomas Kunzfeld.
For more information please see http://zool33.uni-graz.at/artlife or contact Thomas Schmickl at (thomas.schmickl@uni-graz.at).