Uploaded March 2025 | Updated September 2026, 3 weeks ago
We are happy to release an update for the Aerial Gym Simulator.
Code: github.com/ntnu-arl/aerial_gym_simulator
The new update includes support for multi-linked embodiments, with fixed, reconfigurable (active), and soft (passive) joints for simulated multirotors. A faithful simulation model of a compliant robot Morphy(youtube.com/watch?v=C6l7Vklbc9k) and models for active reconfigurable multirotor platforms are added!
We provide scripts for training:
- State-based RL policies for position setpoint tracking including end-to-end methods
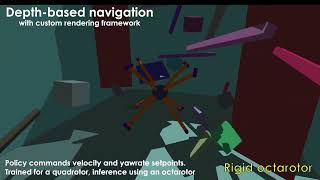
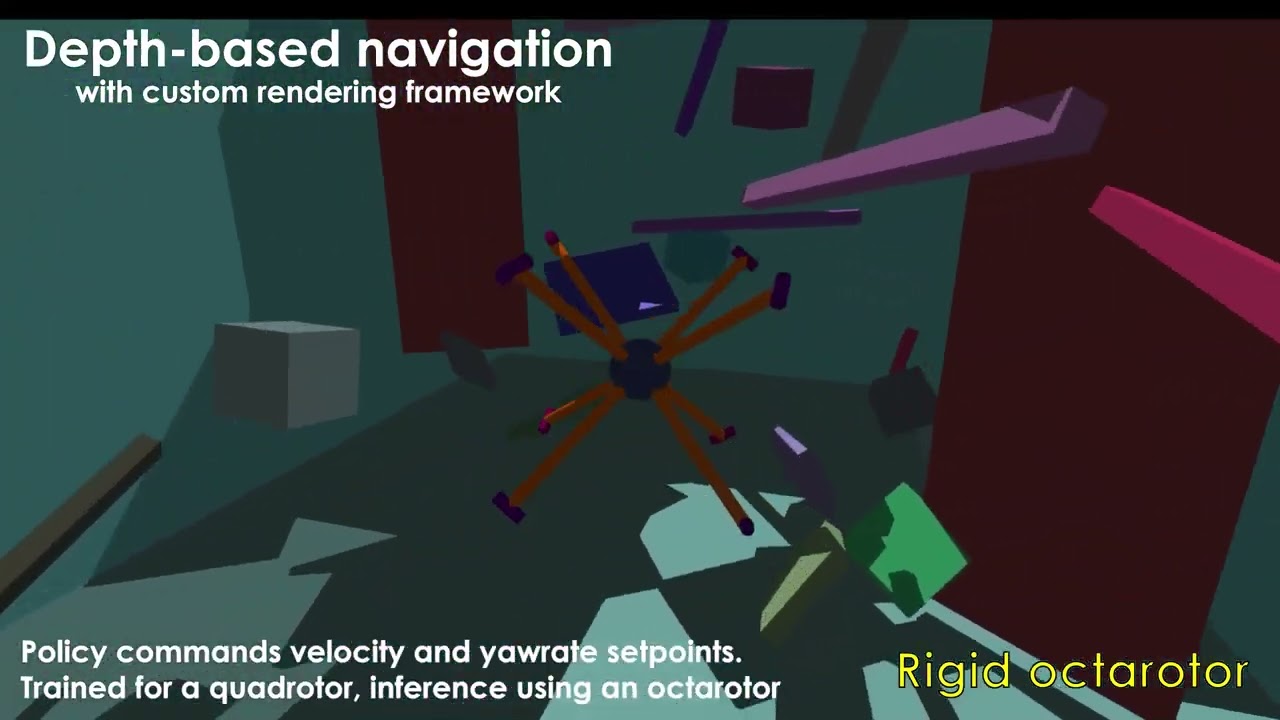
- Vision (depth) based RL-policies for navigation of cluttered environments
- Joint-aware policies for soft drones that minimize oscillations of compliant joints
- Joint and motor control policies for reconfigurable systems for robot-shape and position control
Newer capabilities to query face and vertex indices and surface normal information are added to the rendering framework alongside the capability to query user-defined vertex-level annotations from the environment.
Scripts to deploy trained policies on real robots are provided alongside network model files for easy reproducibility.
We are happy to release an update for the Aerial Gym Simulator.
Code: github.com/ntnu-arl/aerial_gym_simulator
The new update includes support for multi-linked embodiments, with fixed, reconfigurable (active), and soft (passive) joints for simulated multirotors. A faithful simulation model of a compliant robot Morphy(youtube.com/watch?v=C6l7Vklbc9k) and models for active reconfigurable multirotor platforms are added!
We provide scripts for training:
- State-based RL policies for position setpoint tracking including end-to-end methods
- Vision (depth) based RL-policies for navigation of cluttered environments
- Joint-aware policies for soft drones that minimize oscillations of compliant joints
- Joint and motor control policies for reconfigurable systems for robot-shape and position control
Newer capabilities to query face and vertex indices and surface normal information are added to the rendering framework alongside the capability to query user-defined vertex-level annotations from the environment.
Scripts to deploy trained policies on real robots are provided alongside network model files for easy reproducibility.