Uploaded February 2019 | Updated September 2026, 3 weeks ago
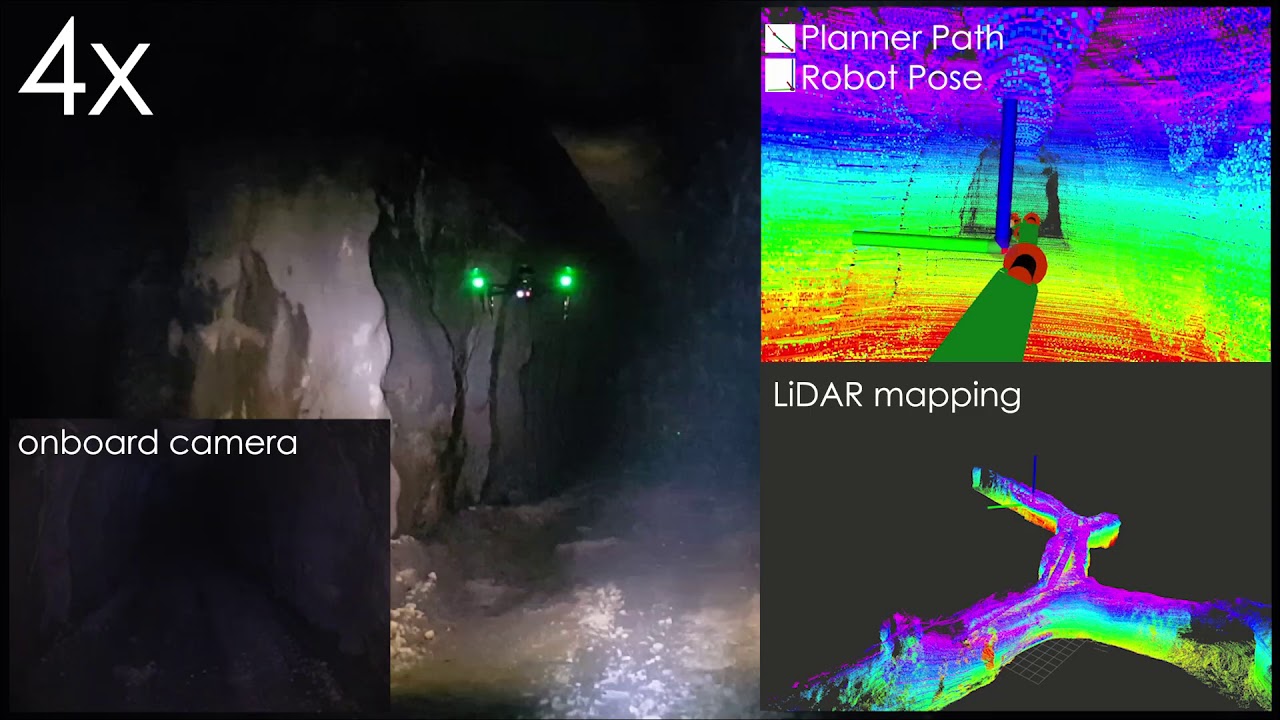
In this work we present new results on long-term autonomous exploration and mapping of subterranean settings and specifically underground mines using aerial robots. An aerial robot capable of sensing-degraded localization and mapping utilizes a new graph search-based path planning algorithm to ensure efficient and smooth exploration even in complex subterranean settings. The particular mission took place at the Production Level of an active underground metal mine in Northern Nevada. The derived results provide accurate map representations that in turn allow volumetric calculations and thus key information for mine planning. Furthermore, the onboard vision system can support the detection of artifacts.
In this work we present new results on long-term autonomous exploration and mapping of subterranean settings and specifically underground mines using aerial robots. An aerial robot capable of sensing-degraded localization and mapping utilizes a new graph search-based path planning algorithm to ensure efficient and smooth exploration even in complex subterranean settings. The particular mission took place at the Production Level of an active underground metal mine in Northern Nevada. The derived results provide accurate map representations that in turn allow volumetric calculations and thus key information for mine planning. Furthermore, the onboard vision system can support the detection of artifacts.