Uploaded October 2018 | Updated September 2026, 3 weeks ago
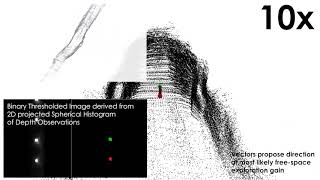
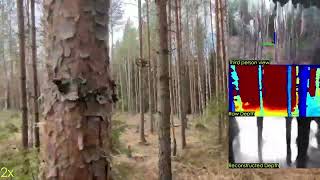
In this work, we present an approach for the detection of the direction of free space in order to improve the efficiency of robotic exploration by exploiting the history of free space calculations. The measurements may come from any range-sensing system, such as a LiDAR or a stereo camera (in this video: based on a Velodyne PuckLITE). The method utilizes a sliding-window history of the robot's pose estimates and the depth measurements to find areas of sparse sensor returns near the end of the robot's perception and thus determines the direction to these areas. This allows the proposal of vectors towards the probable directions of free space due to the consistency of sensor readings with the shape of the environment. This history-aware free space detection can then enhance the operation of an exploration path planning module and optimizes the efficiency of aerial robotic exploration of underground mines and other multi-branched and large-scale subterranean settings.
In this work, we present an approach for the detection of the direction of free space in order to improve the efficiency of robotic exploration by exploiting the history of free space calculations. The measurements may come from any range-sensing system, such as a LiDAR or a stereo camera (in this video: based on a Velodyne PuckLITE). The method utilizes a sliding-window history of the robot's pose estimates and the depth measurements to find areas of sparse sensor returns near the end of the robot's perception and thus determines the direction to these areas. This allows the proposal of vectors towards the probable directions of free space due to the consistency of sensor readings with the shape of the environment. This history-aware free space detection can then enhance the operation of an exploration path planning module and optimizes the efficiency of aerial robotic exploration of underground mines and other multi-branched and large-scale subterranean settings.