Uploaded September 2025 | Updated September 2026, 3 weeks ago
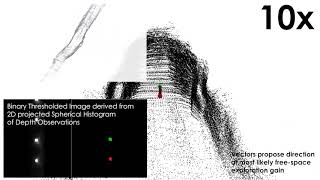
Efficient exploration of unknown environments is crucial for autonomous robots, especially in confined and large-scale scenarios with limited communication. To address this challenge, we propose a collaborative exploration framework for a marsupial ground-aerial robot team that leverages the complementary capabilities of both platforms. The framework employs a graph-based path planning algorithm to guide exploration and deploy the aerial robot in areas where its expected gain significantly exceeds that of the ground robot, such as large open spaces or regions inaccessible to the ground platform, thereby maximizing coverage and efficiency. To facilitate large-scale spatial information sharing, we introduce a bandwidth-efficient, task-driven map compression strategy. This method enables each robot to reconstruct resolution-specific volumetric maps while preserving exploration-critical details, even at high compression rates. By selectively compressing and sharing key data, communication overhead is minimized, ensuring effective map integration for collaborative path planning. Simulation and real-world experiments validate the proposed approach, demonstrating its effectiveness in improving exploration efficiency while significantly reducing data transmission.
Map compression code: github.com/ntnu-arl/pcl-vae