Uploaded May 2018 | Updated September 2026, 1 week ago
ICRA 2018 Spotlight Video
Interactive Session Tue PM Pod L.1
Authors: Shao, Zhanpeng; Li, You-Fu; GUO, Yao; Yang, Jianyu; Wang, Zhenhua
Title: A Hierarchical Model for Action Recognition Based on Body Parts
Abstract:
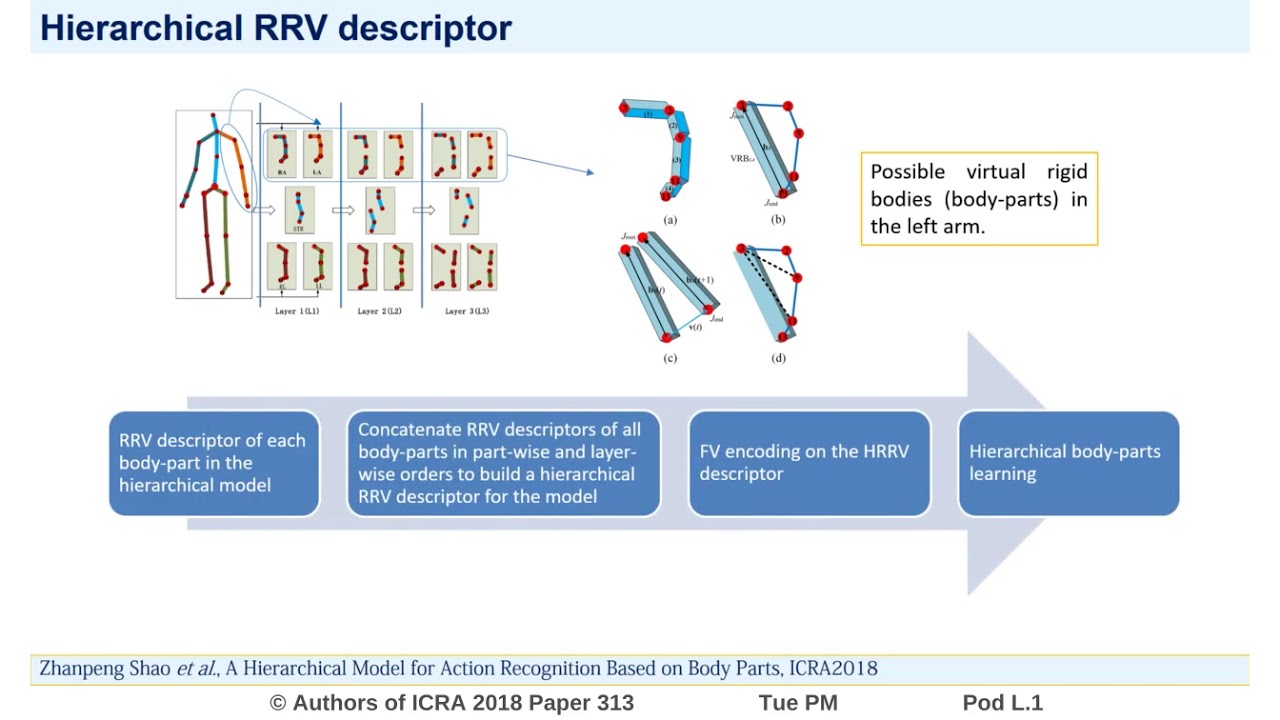
As increasing attention is paid on human action recognition from skeleton data, this paper focuses on such tasks by proposing a hierarchical model to discover the structure information of body-parts involved in human actions. Considering human actions as simultaneous motions of different body-parts of the human skeleton, we propose a hierarchical model to simultaneously apply discriminative body-parts selection at a same scale and group coupling of bundles of body-parts at different scales, while we decompose the human skeleton into a hierarchy of body-parts of varying scales. To represent such hierarchy of body-parts, we accordingly build a hierarchical RRV (Rotation and Relative Velocity) descriptors. The hierarchical representations encoded by Fisher vectors of the hierarchical RRV descriptors are properly formulated into the hierarchical model via the proposed hierarchical mixed norm, to apply sparse selection of body-parts and regularize the structure of such hierarchy of body-parts. The extensive evaluations on three challenging datasets demonstrate the effectiveness of our proposed approach, which achieves superior performance compared to state-of-the-art results on different sizes of datasets, showing it is more widely applicable than existing approaches.
ICRA 2018 Spotlight Video
Interactive Session Tue PM Pod L.1
Authors: Shao, Zhanpeng; Li, You-Fu; GUO, Yao; Yang, Jianyu; Wang, Zhenhua
Title: A Hierarchical Model for Action Recognition Based on Body Parts
Abstract:
As increasing attention is paid on human action recognition from skeleton data, this paper focuses on such tasks by proposing a hierarchical model to discover the structure information of body-parts involved in human actions. Considering human actions as simultaneous motions of different body-parts of the human skeleton, we propose a hierarchical model to simultaneously apply discriminative body-parts selection at a same scale and group coupling of bundles of body-parts at different scales, while we decompose the human skeleton into a hierarchy of body-parts of varying scales. To represent such hierarchy of body-parts, we accordingly build a hierarchical RRV (Rotation and Relative Velocity) descriptors. The hierarchical representations encoded by Fisher vectors of the hierarchical RRV descriptors are properly formulated into the hierarchical model via the proposed hierarchical mixed norm, to apply sparse selection of body-parts and regularize the structure of such hierarchy of body-parts. The extensive evaluations on three challenging datasets demonstrate the effectiveness of our proposed approach, which achieves superior performance compared to state-of-the-art results on different sizes of datasets, showing it is more widely applicable than existing approaches.