Uploaded October 2026 | Updated November 2026, 3 hours ago
Modern network engineers have more options than ever for testing changes before they reach production: virtual network operating systems, containerized labs, topology-as-code, CI/CD pipelines, and increasingly, network digital twins. But these approaches don’t all answer the same questions.
Over the past year, I built an internal network emulation platform designed to create realistic, multi-vendor network environments on demand. The goal was straightforward: make it easy to reproduce networks, test changes, inject failures, and validate behavior before touching production. Building it exposed an important distinction between emulating a network and modeling one.
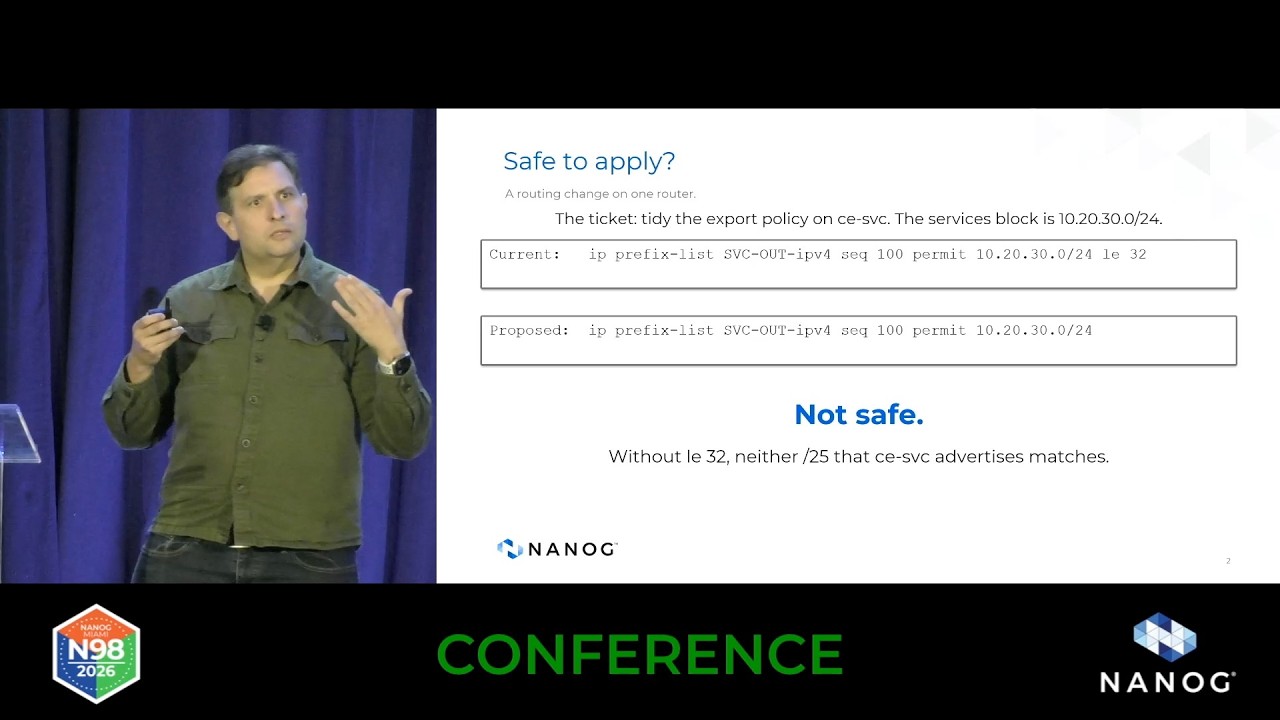
This session explores that distinction through practical examples and lessons learned. We’ll look at where network emulation works exceptionally well, where its fidelity begins to break down, and why simply running more realistic virtual devices doesn’t necessarily produce a better model of production behavior.
We’ll then examine how behavioral modeling and digital twins approach the problem differently, particularly for questions such as reachability, policy changes, failure impact, and predicting the consequences of configuration changes.
Rather than arguing that one approach replaces the other, this talk will show how emulation, automated validation, and network modeling can complement each other—and what I learned trying to build a system that uses all three.
Craig Johnson:
Craig Johnson is a Principal Architect at Forward Networks, where he focuses on cloud strategy, network architecture, automation, and emerging technologies.
With more than 25 years of experience in networking and infrastructure, Craig has worked across enterprise networking, service providers, cloud platforms, and network security. His work spans both traditional network engineering and modern infrastructure, with a particular focus on making complex environments easier to understand, automate, and operate.
Craig is an active contributor to the networking community, with interests in network automation, digital twins, open-source infrastructure, and the practical application of AI to network operations. He regularly speaks at industry events and enjoys building tools and platforms that solve real engineering problems.
Modern network engineers have more options than ever for testing changes before they reach production: virtual network operating systems, containerized labs, topology-as-code, CI/CD pipelines, and increasingly, network digital twins. But these approaches don’t all answer the same questions.
Over the past year, I built an internal network emulation platform designed to create realistic, multi-vendor network environments on demand. The goal was straightforward: make it easy to reproduce networks, test changes, inject failures, and validate behavior before touching production. Building it exposed an important distinction between emulating a network and modeling one.
This session explores that distinction through practical examples and lessons learned. We’ll look at where network emulation works exceptionally well, where its fidelity begins to break down, and why simply running more realistic virtual devices doesn’t necessarily produce a better model of production behavior.
We’ll then examine how behavioral modeling and digital twins approach the problem differently, particularly for questions such as reachability, policy changes, failure impact, and predicting the consequences of configuration changes.
Rather than arguing that one approach replaces the other, this talk will show how emulation, automated validation, and network modeling can complement each other—and what I learned trying to build a system that uses all three.
Craig Johnson:
Craig Johnson is a Principal Architect at Forward Networks, where he focuses on cloud strategy, network architecture, automation, and emerging technologies.
With more than 25 years of experience in networking and infrastructure, Craig has worked across enterprise networking, service providers, cloud platforms, and network security. His work spans both traditional network engineering and modern infrastructure, with a particular focus on making complex environments easier to understand, automate, and operate.
Craig is an active contributor to the networking community, with interests in network automation, digital twins, open-source infrastructure, and the practical application of AI to network operations. He regularly speaks at industry events and enjoys building tools and platforms that solve real engineering problems.