Uploaded May 2025 | Updated November 2026, 51 minutes ago
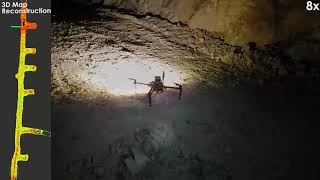
This paper introduces a novel semantics-aware inspection planning policy derived through deep reinforcement learning. Reflecting the fact that within autonomous informative path planning missions in unknown environments, it is often only a sparse set of objects of interest that need to be inspected, the method contributes an end-to-end policy that simultaneously performs semantic object visual inspection combined with collision-free navigation. Assuming access only to the instantaneous depth map, the associated segmentation image, the ego-centric local occupancy, and the history of past positions in the robot's neighborhood, the method demonstrates robust generalizability and successful crossing of the sim2real gap. Beyond simulations and extensive comparison studies, the approach is verified in experimental evaluations onboard a flying robot deployed in novel environments with previously unseen semantics and overall geometric configurations.
This paper introduces a novel semantics-aware inspection planning policy derived through deep reinforcement learning. Reflecting the fact that within autonomous informative path planning missions in unknown environments, it is often only a sparse set of objects of interest that need to be inspected, the method contributes an end-to-end policy that simultaneously performs semantic object visual inspection combined with collision-free navigation. Assuming access only to the instantaneous depth map, the associated segmentation image, the ego-centric local occupancy, and the history of past positions in the robot's neighborhood, the method demonstrates robust generalizability and successful crossing of the sim2real gap. Beyond simulations and extensive comparison studies, the approach is verified in experimental evaluations onboard a flying robot deployed in novel environments with previously unseen semantics and overall geometric configurations.