Uploaded May 2017 | Updated September 2026, 2 weeks ago
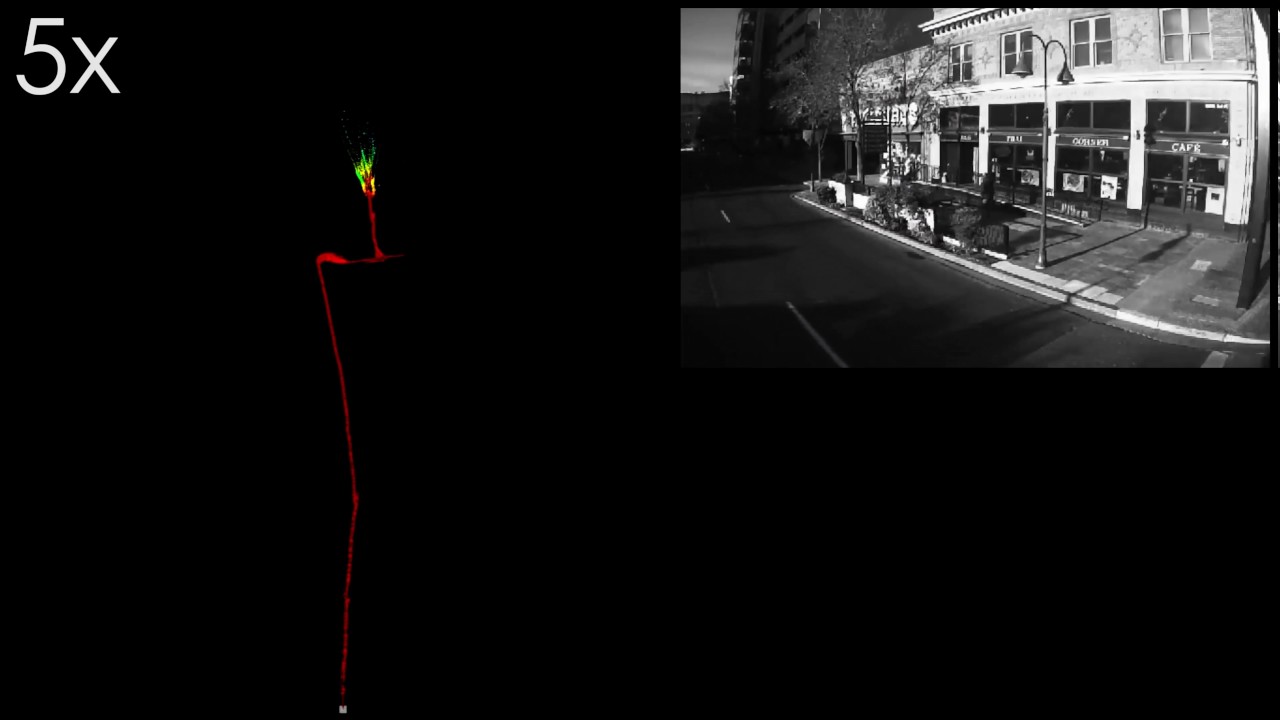
This video presents preliminary results on GPS-denied localization and object detection (including cars, pedestrians and traffic signs) onboard an electric bus driving in the city of Reno.
The electric bus is a product of Proterra Inc (proterra.com/) and used by RTC (rtcwashoe.com/).
The work is part of the Intelligent Mobility Project coordinated by the University of Nevada, Reno (http://www.unr.edu/).
Details for the work (this and further ongoing activities) will soon be released in the form of a Technical Report to be released by August 2017.
For technical details please visit: autonomousrobotslab.com
This video presents preliminary results on GPS-denied localization and object detection (including cars, pedestrians and traffic signs) onboard an electric bus driving in the city of Reno.
The electric bus is a product of Proterra Inc (proterra.com/) and used by RTC (rtcwashoe.com/).
The work is part of the Intelligent Mobility Project coordinated by the University of Nevada, Reno (http://www.unr.edu/).
Details for the work (this and further ongoing activities) will soon be released in the form of a Technical Report to be released by August 2017.
For technical details please visit: autonomousrobotslab.com