Uploaded May 2018 | Updated November 2026, 1 hour ago
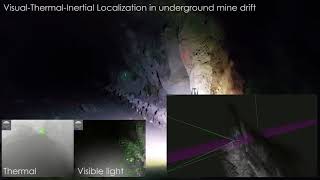
In this video we present results from a field deployment of robotic systems inside an underground mine.
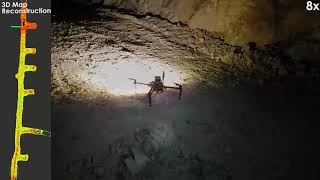
The deployment involved the autonomous operation, exploration and mapping of underground mine drifts and headings using two aerial robots.
The first robot based its operation on the fusion of visible-light and thermal camera data alongside IMU cues, while the second robot employed LiDAR as a prime sensing modality. Both robotic systems demonstrated the ability to operate in the challenging underground environment.
In addition, we evaluated the ability of a comprehensive LiDAR, visual- and thermal-inertial sensor system to provide persistent localization when ferried onboard a truck navigating across the mine drifts.
Such field deployments inside underground mines allow the specific analysis regarding the required improvements and technological breakthroughts towards fully autonomous and long-term subterranean robots. It is expected that, among others, these robots will be able to greatly support the needs and goals of the mining industry.
Find out more: autonomousrobotslab.com
In this video we present results from a field deployment of robotic systems inside an underground mine.
The deployment involved the autonomous operation, exploration and mapping of underground mine drifts and headings using two aerial robots.
The first robot based its operation on the fusion of visible-light and thermal camera data alongside IMU cues, while the second robot employed LiDAR as a prime sensing modality. Both robotic systems demonstrated the ability to operate in the challenging underground environment.
In addition, we evaluated the ability of a comprehensive LiDAR, visual- and thermal-inertial sensor system to provide persistent localization when ferried onboard a truck navigating across the mine drifts.
Such field deployments inside underground mines allow the specific analysis regarding the required improvements and technological breakthroughts towards fully autonomous and long-term subterranean robots. It is expected that, among others, these robots will be able to greatly support the needs and goals of the mining industry.
Find out more: autonomousrobotslab.com