Autonomous Exploration and Mapping in Underground Mines using Aerial Robots @autonomousrobotslab
Autonomous Exploration and Mapping in Underground Mines using Aerial Robots  @autonomousrobotslab
Uploaded January 2019 | Updated November 2026, 52 minutes ago
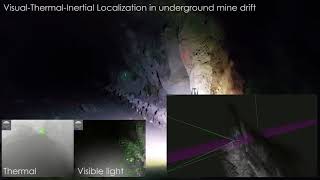
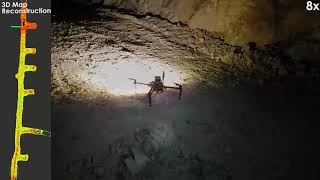
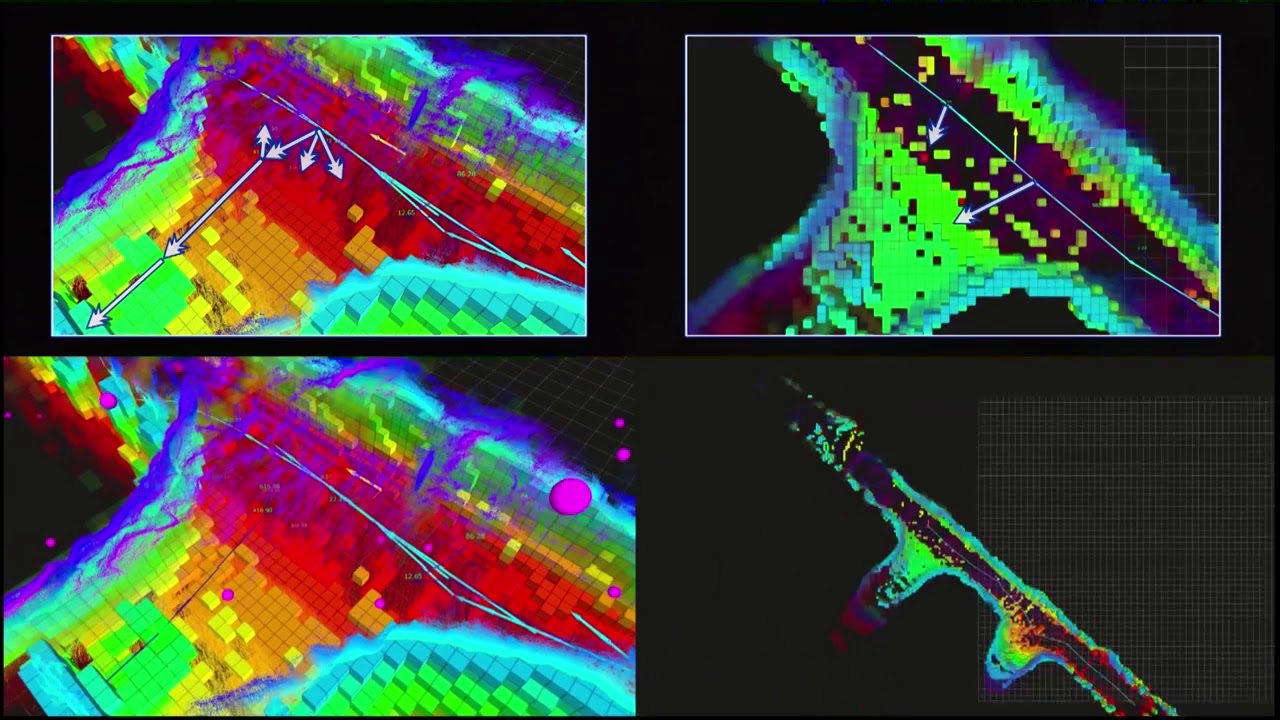
This video presents our recent results on Autonomous Exploration and Mapping in Underground Mines using Aerial Robots. It is research activity in the framework of the DARPA Subterranean Challenge.
Autonomous Exploration and Mapping in Underground Mines using Aerial RobotsCOHORT: CoOperation for HeterOgeneous Robot Teams - How it WorksDistributed Radiation Field Estimation and Informative Path Planning for Nuclear CharacterizationThe Reconfigurable Aerial Robotic Chain: Shape and Motion PlanningField Deployment of Autonomous Aerial Robots in Underground MinesTask-Driven Design Optimization of Passively Morphing Quadrotors for Contact-Mediated Gap TraversalThe Reconfigurable Aerial Robotic Chain: Modeling and ControlPreliminary Results on GPS-denied Localization and Traffic Detection onboard an Electric BusSemantically-enhanced Deep Collision Prediction for Autonomous Navigation - How it WorksLearning-based Path Planning for Autonomous Exploration of Subterranean EnvironmentsLiDAR-Visual-Inertial Fused Mapping for Cars - Preliminary Result - UNR GarageICRA2021: Hypergame-Based Adaptive Behavior Path Planning fr Combined Exploration & Visual Search
Kostas Alexis |

Autonomous Exploration and Mapping in Underground Mines using Aerial Robots

SHARE TO X SHARE TO REDDIT SHARE TO FACEBOOK WALLPAPER