Uploaded May 2018 | Updated September 2026, 2 weeks ago
ICRA 2018 Spotlight Video
Interactive Session Wed PM Pod Q.7
Authors: Huang, Kaihong; Stachniss, Cyrill
Title: On Geometric Models and Their Accuracy for Extrinsic Sensor Calibration
Abstract:
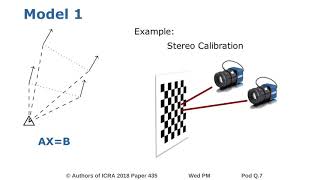
Extrinsic sensor calibration is an important task in robotics. There are various ways to perform the calibration task, but it often remains unclear which methods are better than the others. In this paper, we provide a systematic study about the calibration accuracy of three types of calibration methods, each represented by an abstract geometric model based on the sensor configuration and the calibration setup. We discuss the advantages and disadvantages of each model and perform a rigorous study on their noise sensitivity from a geometric perspective. As a result, we can reveal and quantify the relative calibration accuracies of the three models, thus answering the question of which model is better and why?. Beside our analytical analysis, we also provide numerical simulation experiments that validate our findings.
ICRA 2018 Spotlight Video
Interactive Session Wed PM Pod Q.7
Authors: Huang, Kaihong; Stachniss, Cyrill
Title: On Geometric Models and Their Accuracy for Extrinsic Sensor Calibration
Abstract:
Extrinsic sensor calibration is an important task in robotics. There are various ways to perform the calibration task, but it often remains unclear which methods are better than the others. In this paper, we provide a systematic study about the calibration accuracy of three types of calibration methods, each represented by an abstract geometric model based on the sensor configuration and the calibration setup. We discuss the advantages and disadvantages of each model and perform a rigorous study on their noise sensitivity from a geometric perspective. As a result, we can reveal and quantify the relative calibration accuracies of the three models, thus answering the question of which model is better and why?. Beside our analytical analysis, we also provide numerical simulation experiments that validate our findings.