Uploaded December 2022 | Updated September 2026, 1 week ago
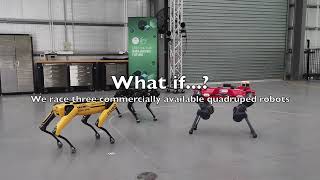
What if we race three commercially available quadruped robots for a bit of fun...? Out of the box configuration, 'full sticks forward' on the remotes on flat ground. Hope you enjoy the results ;-)
Note: Flat ground is not the terrain these robots have been designed for, so this is not meant to be an evaluation of their actual performance.
Robot operators: Tom Molnar on ANYbotics Anymal C, Fletcher Talbot on Boston Dynamics Spot and Ryan Steindl on Ghost Robotics Vision 60.
Videography and commentary: Fabio Ruetz
Find out more about our work: https://research.csiro.au/robotics/
What if we race three commercially available quadruped robots for a bit of fun...? Out of the box configuration, 'full sticks forward' on the remotes on flat ground. Hope you enjoy the results ;-)
Note: Flat ground is not the terrain these robots have been designed for, so this is not meant to be an evaluation of their actual performance.
Robot operators: Tom Molnar on ANYbotics Anymal C, Fletcher Talbot on Boston Dynamics Spot and Ryan Steindl on Ghost Robotics Vision 60.
Videography and commentary: Fabio Ruetz
Find out more about our work: https://research.csiro.au/robotics/